Sensors
RaiSim supports these sensor workflows:
- URDF-attached sensors for robots. Sensor metadata is loaded from a sensor XML file attached to a URDF link. This is the right workflow for IMU, RGB, depth, and spinning LiDAR sensors that should move with an articulated system.
- rayrai-rendered RGB, depth and segmentation sensors for camera observations. When rayrai is available, use in-process rayrai rendering with
Sensor::MeasurementSource::MANUALfor camera sensor buffers. This is the recommended path for rendered images, screenshots, and dataset generation. - World-level CPU depth-camera capture only as a deterministic headless fallback.
World::captureDepthCameracasts CPU rays from an arbitrary camera pose and returns depth, object segmentation, optional hit points, and a timestamp without requiring a renderer.
The CPU ray-query paths are single-threaded and deterministic. Use in-process rayrai rendering for RGB/depth images when it is available. A connected TCP visualizer can also render due MANUAL cameras and return their images to RaisimServer; the server applies the sensor noise when committing those buffers.
Sensor frames and camera convention
Camera and LiDAR sensors use the RaiSim sensor-frame convention:
+X: forward+Y: left+Z: up
Camera depth is the distance along the camera +X axis, not the Euclidean ray length. This matches the existing DepthCamera convention and is convenient for pinhole camera models.
How to attach a sensor to a link
Before further explanations, we clarify some terms used throughout this page. sensor means one measurement stream, such as an RGB camera, a depth camera, an IMU, or a LiDAR scan. sensor_set means a set of sensors contained in one link. For example, an Intel RealSense-like link can contain RGB, depth, and IMU sensors.
Create a link for a sensor set and give it a sensor attribute:
<link name="realsense_d435" sensor="realsense435.xml"/>Such a link must be empty: its inertial, visual and collision elements are defined in the sensor XML file. The sensor XML file should be stored in the same directory as the URDF file. If it is not found, RaiSim searches [urdf_dir]/sensor, [urdf_dir]/sensors, [urdf_dir]/.., and [urdf_dir]/../sensors. For a URDF given as a string, the resource directory passed to World::addArticulatedSystem() takes the place of [urdf_dir]. An example sensor file is realsense435.xml. An example URDF is anymal_sensored.urdf.
Measurement source and update modes
The update method is selected with raisim::Sensor::setMeasurementSource:
RAISIM: measurement is computed by RaiSim. The owning articulated system refreshes it duringWorld::integrate()on a fixed grid of deadlines1 / update_rateapart, at the first step that reaches each deadline (see Update timing). This is the default for IMU and spinning LiDAR sensors.DepthCameraandSegmentationCamerasupport RaiSim-side CPU ray updates, but use this for headless fallback rather than for rendered camera images when rayrai is available.RGBCameracannot use it.MANUAL: user code writes the buffers. This is the default for RGB, depth and segmentation cameras. Use it for in-process rayrai rendering or real hardware integration.
Update timing
RaiSim-sourced IMUs, depth cameras and LiDARs count their deadlines in physics steps: the time of a deadline is the sum of the time steps since the grid started, not the world time. A sensor takes each deadline at the first step that reaches it and drops the deadlines a step goes past, without shifting the grid. It takes at most one sample per step, so its long-run rate equals update_rate up to the physics rate, even when the period is not a multiple of the time step. A 30 Hz depth camera at 1000 Hz is updated 34, 33, 33, 34, 33, 33, ... steps apart, 30 times per simulated second, and a 500 Hz IMU at 2000 Hz exactly every fourth step, without slipping.
The world time stamps the samples (getUpdateTimeStamp()). Changing it with World::setWorldTime() between steps does not move the grid, so a world clock that disagrees with the time step (time kept in whole nanoseconds at 3000 Hz) does not slip the samples. A step that ends before the last step the sensor counted starts a new episode: the grid starts again with an update at once. Setting the world time back by more than one step does this; setting it back by one step or less goes unnoticed, as the next step then ends at or after the last one (at the same time, it counts as already done). The grid also starts again, with an update at once, when setUpdateRate() changes the rate. When the world time moves forward by more than one and a half time steps between two steps the sensor counts (it was not updated for some steps, for example while its source was MANUAL, or the world time was set forward), that time counts as physics time. A spinning LiDAR's head still turns by the world time between its updates (see Spinning LiDAR). Force and tactile sensors keep their own acquisition clock.
MANUAL RGB, depth and segmentation cameras also retain a nominal sample grid when scheduled through Sensor::isUpdateDue(worldTime) and setUpdateTimeStamp(acquisitionTime). The first acknowledged image anchors the grid. Later images retain the remainder after their deadlines: at 1000 Hz, a 30 Hz camera uses 34, 33, 33, ... step intervals instead of waiting 34 steps after every image (29.4 Hz). A 300 Hz camera uses 4, 3, 3, ... steps; relative to its first image, updates occur at 0, 4, 7, 10, 14, ... ms. Polling does not consume a deadline, and acknowledging the same image twice does not advance it twice. Missed deadlines are skipped without shifting the remaining grid.
RaisimServer schedules viewer images from a compensated clock advanced by the configured physics time steps, for cameras on both world robots and visual-only articulated systems. It records this clock and the world timestamp when it requests an image. A delayed reply acknowledges that acquisition time, so render or transport delays do not restart the period. getUpdateTimeStamp() remains the acquisition world time, not the reply arrival time. Checkpoints preserve the camera grid and its clock. When a camera's image size (or a segmentation camera's type) changes, the server sends the new properties to the viewer before requesting the camera again; an image the viewer was rendering with the old properties is dropped and does not count as a sample.
For viewer scheduling, a world-time correction applied after an integration step and no larger than half that step leaves the camera clock unchanged. Larger jumps, and time changes without an intervening integration since the preceding clock edit, adjust it. Setting the current time again has no effect. A backward acquisition timestamp or a rate/source change establishes a new grid at the next acknowledged image.
Outside RaisimServer, the public polling/acknowledgment API uses the timestamps the application supplies. In-process rendering remains application-driven; use this API when enforcing a camera update rate.
There is no VISUALIZER measurement source in the RaiSim API. TCP camera requests use MANUAL sensors: a connected visualizer renders requested frames, and RaisimServer writes the returned images and acquisition timestamps.
Recommended RGB/depth usage with rayrai sets camera sensors to MANUAL and lets the renderer fill or read back the buffers. See Using sensors with rayrai for a complete example. Use RAISIM CPU depth updates only when rayrai is not available or when a deterministic headless ray-query fallback is required.
For RGB sensors, RaiSim does not synthesize color in the physics engine. Write the buffer manually, preferably from in-process rayrai rendering when it is available, or from real hardware:
auto* rgb = sensorSet->getSensor<raisim::RGBCamera>("color");
rgb->setMeasurementSource(raisim::Sensor::MeasurementSource::MANUAL);
std::vector<char> rgba(size_t(rgb->getProperties().width) *
                       size_t(rgb->getProperties().height) * 4);
rgb->setImageBuffer(rgba);
When reading sensor buffers from another user-managed thread, use std::scoped_lock:
{
  std::scoped_lock lock(*depth);
  const auto& image = depth->getDepthArray();
  // read image here
}
Depth camera
raisim::DepthCamera stores a float array with width * height entries. Finite values are plane depth in meters. CPU ray captures use NaN for missing pixels; clean raw renderer captures may retain a different missing-return encoding. Active noise models normalize invalid depths to NaN.
CPU-only fallback update:
auto* depth = anymal->getSensorSet("depth_camera_front_camera_parent")
                ->getSensor<raisim::DepthCamera>("depth");
depth->setMeasurementSource(raisim::Sensor::MeasurementSource::RAISIM);

world.integrate();     // refreshes the image at the sensor's update rate
depth->update(world);  // optional: ray-cast a new image now

const auto& z = depth->getDepthArray();
const int w = depth->getProperties().width;
const int h = depth->getProperties().height;
float centerDepth = z[(h / 2) * w + (w / 2)];
Convert depth to a point cloud:
std::vector<raisim::Vec<3>> pointsWorld;
depth->depthToPointCloud(depth->getDepthArray(), pointsWorld, false);

std::vector<raisim::Vec<3>> pointsSensor;
depth->depthToPointCloud(depth->getDepthArray(), pointsSensor, true);
The camera intrinsics are defined by width, height, horizontal field of view (hFOV), and optional pixel offsets. If you modify camera properties after loading, call updateRayDirections() before the next update.
RGB camera
raisim::RGBCamera stores an image buffer with width * height * 4 bytes (4 bytes per pixel, rows contiguous). RaiSim itself does not render RGB and does not interpret the channel order; rayrai's Camera::getRawImage() writes BGRA. Use rayrai or manual hardware input; update() is a fatal error for an RGB camera.
Manual buffer update:
auto* rgb = anymal->getSensorSet("depth_camera_front_camera_parent")
              ->getSensor<raisim::RGBCamera>("color");

auto& prop = rgb->getProperties();
std::vector<char> rgba(size_t(prop.width) * size_t(prop.height) * 4);

// Fill rgba as R, G, B, A bytes.
for (int y = 0; y < prop.height; ++y) {
  for (int x = 0; x < prop.width; ++x) {
    const size_t k = 4 * (size_t(y) * size_t(prop.width) + size_t(x));
    rgba[k + 0] = char(255);
    rgba[k + 1] = char(0);
    rgba[k + 2] = char(0);
    rgba[k + 3] = char(255);
  }
}

rgb->setImageBuffer(rgba);
Segmentation camera
raisim::SegmentationCamera reports what each pixel sees. It fills up to three int32 images of width * height values, in rows from the top-left pixel (index row * width + col):
- the object image holds the world index of the object (
Object::getIndexInWorld(),World::getObject(index)), - the body image holds the body of that object, in
ArticulatedSystem::getBodyNames()order (0 for single bodies, compounds, height maps and deformables), - the label image holds the semantic label of that body.
Pixels that see nothing between the near and the far plane hold SegmentationCamera::kBackground (-1) in every image. Rayrai visuals that are not RaiSim objects, drawn only when a render includes visualization objects, hold SegmentationCamera::kNotWorldObject (-2) as object and body index and label 0, unless Visuals::setSegmentationIds() gives them other ids.
The segmentation type selects the images: SEMANTIC fills the label image, INSTANCE the object and body images, and PANOPTIC (the default) all three. getObjectImage(), getBodyImage() and getLabelImage() return empty vectors for the images the type does not select. A world index is the object's index when the image was taken: World::removeObject() moves the last object into the index it frees.
Labels and classes
A label is a non-negative integer; 0 means unlabeled. The world keeps a table of class names for them:
const int32_t robotClass = world.addSegmentationClass("robot");
robot->setSegmentationLabel(robotClass);  // every body of the robot
robot->setBodySegmentationLabel("gripper", world.addSegmentationClass("gripper"));
box->setSegmentationLabel(world.addSegmentationClass("box"));

const auto& labels = camera->getLabelImage();
const std::string& name = world.getSegmentationClassName(labels[pixel]);
addSegmentationClass() returns the label a name already has, or the next free label (labels start at 1). setSegmentationClassName(label, name) names a label of your choice. A body label set with setBodySegmentationLabel() takes precedence over the object label; clearBodySegmentationLabels() removes them. Links merged into their parent through fixed joints are part of the parent body. World XML exports and checkpoints keep the labels and the class table.
When displaying the label image, all objects with the same semantic label have the same color, regardless of their RGB appearance. For example, two boxes labeled Box share a color. Colorize the object image instead to give each object instance its own color. The segmentation camera example shows both modes beside the RGB image.
URDF, XML and .rscene
A URDF link declares a segmentation camera like a depth camera, with an optional <segmentation type="..."> (semantic, instance or panoptic):
<sensor name="segmentation" type="segmentation" update_rate="30">
  <origin xyz="0.1 0 0" rpy="0 0 0"/>
  <camera horizontal_fov="1.2">
    <image width="640" height="480"/>
    <clip near="0.05" far="20"/>
  </camera>
  <segmentation type="panoptic"/>
</sensor>
The projection and lens attributes of depth cameras apply as well. In a world XML file, an object takes segmentation_label="4" or segmentation_class="box" (one of the two), an articulated system also takes per-body labels, and <segmentation_classes> names labels:
<raisim version="1.0">
  <segmentation_classes>
    <class label="1" name="floor"/>
  </segmentation_classes>
  <objects>
    <ground name="floor" segmentation_label="1"/>
    <articulated_system name="arm" urdf_path="arm.urdf" segmentation_class="robot">
      <body_segmentation body="tip" class="gripper"/>
    </articulated_system>
  </objects>
</raisim>
In a .rscene file, the semanticClass key of an object or articulated record labels it with that class.
Measuring segmentation images
With rayrai, render the camera and read the images back. The images agree pixel for pixel with renderDepthPlaneDistance() from the same camera, without antialiasing, blending, weather or post-processing; a fisheye lens is resampled at the nearest pixel:
auto* camera = robot->getSensorSet("head")->getSensor<raisim::SegmentationCamera>("segmentation");
raisin::Camera renderCamera(*camera);

viewer->renderSegmentation(*camera, renderCamera);  // copies the sensor pose
renderCamera.getRawImage(*camera);                   // fills the sensor's images

std::vector<unsigned char> rgba;
raisim::SegmentationCamera::colorize(camera->getLabelImage(), rgba);  // for display
Camera::readSegmentation() reads the three images into buffers of your own. A connected rayrai_tcp_viewer renders the MANUAL segmentation cameras of a RaisimServer's robots and returns their images, as for RGB and depth cameras.
With the RAISIM source, update(world) casts one ray per pixel from the near to the far plane against the collision bodies of the world, ignoring the body the camera is attached to. Rayrai draws visual meshes, so the two differ where a body's visual and collision shapes differ. Fisheye distortion coefficients are applied by rayrai only, as for depth cameras.
In Python, getObjectImage(), getBodyImage() and getLabelImage() return (height, width) int32 arrays, or None for images the type does not select, and raisimpy.rayrai.Camera.readSegmentation() returns the three rendered images.
Display colors and Python
SegmentationCamera::colorize(ids, rgba, background) gives each non-negative id a fixed color and negative ids the background color (transparent black by default).
camera = robot.getSensorSet("camera_link").getSensor("segmentation")
camera.setMeasurementSource(raisim.SensorMeasurementSource.RAISIM)
world.integrate()
objects = camera.getObjectImage()  # (H, W) int32, -1 for background
labels = camera.getLabelImage()
colors = raisim.SegmentationCamera.colorize(labels)  # (H, W, 4) uint8
mask = objects == table.getIndexInWorld()
Spinning LiDAR
raisim::SpinningLidar uses RaiSim ray casting and returns hit points in the sensor frame. The world helper rayTestLidar performs one frustum-style broadphase for the scan, then raycasts only the candidate bodies.
Typical robot-attached LiDAR update:
auto* lidar = anymal->getSensorSet("lidar_link")
                ->getSensor<raisim::SpinningLidar>("lidar");
lidar->setMeasurementSource(raisim::Sensor::MeasurementSource::RAISIM);  // the default

world.integrate();     // refreshes the scan at the sensor's update rate
lidar->update(world);  // optional: scan now

const auto& scanS = lidar->getScan(); // points in sensor frame
lidar->updatePose();
const auto& p_WS = lidar->getPosition();
const auto& R_WS = lidar->getOrientation();

std::vector<raisim::Vec<3>> scanW;
scanW.reserve(scanS.size());
for (const auto& p_S : scanS) {
  scanW.push_back(p_WS + R_WS * p_S);
}
For custom scanning patterns, use World::rayTestLidar directly. Yaw and pitch are each specified as start angle, signed increment, count. See Ray Test for the exact signature, sampling order, compact-output behavior, and performance considerations.
update() first advances the spinning head with advanceSweep(worldTime), which returns the yaw columns swept since the last update (first, count and direction; a sweep longer than one turn repeats columns) and sets the current yaw and timestamps, and then casts those columns. The first update after the sensor is created or loaded, or after World::setWorldTime() moved the time back before the last update, sweeps the time since world time 0, at most one update interval (1 / update_rate). The rays ignore the collision bodies of the body the LiDAR is mounted on (a link fixed to its parent is part of the parent's body), so a LiDAR inside its link's housing sees past it. Another ray tracer can call advanceSweep() itself, cast the columns against World::getRayCastBodies() (the collision bodies the ray tests see, with their world poses) and store the points with setScan(). rayrai's GPU LiDAR does exactly this and returns the same points as update().
Sensor noise
Robot-mounted RGB, depth, and spinning LiDAR sensors support optional measurement noise. Defaults preserve the clean measurements. Each sensor owns a random stream; resetNoise() restarts it. Seed zero derives a deterministic stream from the sensor's full name and its owning object's stable World id, decorrelating sensors on one or several robots. An unnamed detached sensor has no identity to mix. Nonzero seed values select explicit streams, so matching explicit seeds and models replay the same draws, independently of sensor names.
World::setSensorNoiseSeed(uint64_t) mixes an environment seed into all attached sensor streams. Call it before adding robots, or between complete physics steps to restart existing random streams. Measurements, IMU bias and filters, the acquisition clock and delayed samples are preserved. Use imu->reset() when restarting the complete IMU model is intended. The default World seed is zero; cloned Worlds with the same seeds and object creation order deliberately replay. In parallel environments, set a distinct World seed from the environment index. All 64 seed bits participate; this does not alter individual sensor property seeds. World XML and checkpoints save the environment seed, and checkpoint restoration resumes the saved streams. Resetting properties also resets the stream; for depth, call updateRayDirections() after editing properties. Repeatability is for the same build and sequence of captures; floating-point math can differ between platforms.
Measurement models
| Sensor | Properties | Meaning |
|---|---|---|
| RGB | noiseType, mean, std | Independent Gaussian or uniform read noise per color channel, in normalized intensity units: 0 is black, 1 is full scale. Alpha is preserved. |
| RGB | shotNoise, rowNoiseStd | Independent signal-dependent Gaussian noise with variance shotNoise * intensity, plus a Gaussian offset shared across each row and its three color channels. |
| Depth | noiseType, mean, std, stdDepthSquared | Bias in meters and Gaussian/uniform noise with standard deviation std + stdDepthSquared * z * z, where z is clean optical depth in meters. |
| Depth | resolution, dropoutProbability | Quantization step in meters and independent per-valid-pixel dropout probability. Dropped or out-of-range measurements become NaN. |
| LiDAR | rangeBias, rangeNoiseStd, angularNoiseStd | Range bias and Gaussian range noise in meters; independent Gaussian yaw and pitch errors in radians, applied to the returned sensor-frame hits. |
| LiDAR | resolution, dropoutProbability | Range quantization in meters and independent per-hit dropout. Dropped and out-of-range hits are omitted, preserving the order of surviving hits. |
The legacy World::captureDepthCamera has a separate, reseeded-per-capture noise API and uses a uniform half-range; see Optional deterministic depth noise. For attached sensors, Gaussian and uniform std both mean standard deviation: the uniform interval has half-width sqrt(3) * std. NO_NOISE ignores the additive mean/std parameters; RGB shot/row effects and depth quantization/dropout remain independently configurable. RGB is rounded and clamped to byte values after all noise is added. Depth and LiDAR are quantized after noise, then checked against their configured range. Noisy depths outside the finite float32 storage range become NaN before conversion. Non-finite and missing returns never turn into valid hits. Noise does not change the acquisition timestamp, pose, scan sweep, or alpha channel.
RGB shotNoise is a high photon-count Gaussian approximation in the rendered intensity space, rather than a calibrated photon/electron simulation. It does not model low-light Poisson statistics or an image signal processor. LiDAR angle noise perturbs a hit's reported direction; it does not widen the beam or cast a second ray. These models do not add rolling shutter, motion distortion, multipath, material-dependent return probabilities, or camera/LiDAR latency.
Noise is reproducible on the same platform and build when the scene, capture order, properties and seed match. Floating-point Gaussian transforms may differ between platforms. LiDAR draws are assigned in retained-hit order: a missing or extra hit shifts the draws of subsequent hits, so CPU/GPU scans with different hit sets need not share per-ray errors.
Shipped RealSense sensor definitions explicitly disable camera noise to preserve clean robot captures. Set type="gaussian" or type="uniform" with a nonzero stddev to enable it. Third-party files with existing nonzero noise settings now activate those settings; use type="none" to retain clean captures. Unknown camera noise types raise std::invalid_argument.
Disabled depth models preserve raw input bytes, including the renderer's missing return encoding. Active models normalize non-positive and out-of-clip inputs to NaN. Depth resolution is a quantization step in meters, independent of image width and height.
Configure a depth camera in C++:
auto& p = depth->getProperties();
p.noiseType = decltype(p.noiseType)::GAUSSIAN;
p.std = 0.002;                 // 2 mm at zero distance
p.stdDepthSquared = 0.001;     // sigma is 18 mm at 4 m
p.resolution = 0.001;          // 1 mm depth steps
p.dropoutProbability = 0.01;
p.seed = 101;
depth->updateRayDirections();
For RGB, copy the immutable properties and pass them to setProperties():
auto p = rgb->getProperties();
p.noiseType = decltype(p.noiseType)::GAUSSIAN;
p.std = 0.01;                 // about 2.55 byte levels
p.shotNoise = 0.0001;
p.rowNoiseStd = 0.002;
p.seed = 43;
rgb->setProperties(p);
In URDF sensor XML, camera noise settings belong on an optional <camera><noise> element; LiDAR takes an optional <noise> child of <sensor>. Omitted attributes retain their clean defaults, so effect-only settings such as <noise shot_noise="0.001"/> or <noise dropout_probability="0.01"/> need no dummy read-noise fields. Read noise defaults to NO_NOISE; set type="gaussian" or type="uniform" when configuring additive read noise. Unknown noise types are rejected.
<!-- Inside a depth sensor's <camera>: -->
<noise type="gaussian" mean="0" stddev="0.002"
       std_depth_squared="0.001" resolution="0.001"
       dropout_probability="0.01" seed="101"/>
<!-- Inside an RGB sensor's <camera>: -->
<noise type="gaussian" mean="0" stddev="0.01"
       shot_noise="0.0001" row_noise_std="0.002" seed="43"/>
<!-- Inside a spinning_lidar sensor: -->
<noise range_bias="0.002" range_noise_std="0.01"
       angular_noise_std="0.001" resolution="0.001"
       dropout_probability="0.01" seed="987"/>
Noise is assigned to physical pixels in top-left image order. For a raw bottom-left buffer, call applyNoise(data, size, false); Rayrai passes its flipVertical choice automatically. Resetting the stream before captures in opposite layouts produces the same seeded measurements with reversed row storage. Depth point-cloud conversion expects top-left rows; fisheye rays with a nonpositive forward component have no valid positive optical depth and produce NaN points.
CPU depth/LiDAR update() and Rayrai's sensor-aware getRawImage() / GPU LiDAR capture apply noise automatically, including custom output buffers. CPU DepthCamera::get3DPoints() follows the noisy depth image, including its NaNs. For Rayrai, use depthToPointCloud() to reconstruct measured points; readback does not populate get3DPoints(). The point conversion handles pinhole and fisheye optical depth.
Manual setters such as setImageBuffer(), setDepthArray(), and setScan() keep hardware/playback data unchanged. Call applyNoise() explicitly after a manual setter to synthesize one measurement. Do not call it again after an automatic capture. Raw Camera readbacks without a RaiSim sensor remain clean. Asynchronous raw readbacks can be processed explicitly with the sensor's applyNoise(pointer, size) overload when the returned frame is consumed.
For TCP cameras, the visualizer sends clean pixels and RaiSim applies the model when it commits the received image. The protocol is unchanged; the visualizer's preview remains clean while the sensor buffer contains the noisy measurement. There are no per-pixel allocations; all-disabled models return before processing pixels. Rendering resolution, materials, lighting, and shadow quality are unchanged.
See the sensor noise example for reproducible RGB/depth comparison images and the exact capture calls.
IMU
raisim::InertialMeasurementUnit produces accelerometer and gyroscope measurements for a frame attached to an articulated system. The default is an ideal sensor; bias, noise, bandwidth, quantization, saturation and delivery latency (0 to 60 seconds) are configurable. Sensor measurements do not require enabling inverse dynamics on the robot.
Start with the runnable Example: IMU Sensor Model example. It compares an ideal sensor and a modeled sensor at the same mounting point and writes CSV without a viewer. Server Example: Sensor Suite demonstrates using an IMU alongside rendered cameras and LiDAR.
Reading measurements
With MeasurementSource::RAISIM (the default), read the IMU after world.integrate(). Getters hold the latest delivered sample between updates; a changed measurement value is not a reliable way to detect a new sample.
auto* imu = robot->getSensorSet("base")
                ->getSensor<raisim::InertialMeasurementUnit>("imu");
double lastAcquisition = -1.0;

// Inside the simulation loop:
world.integrate();
const double acquired = imu->getUpdateTimeStamp();
if (acquired >= 0.0 && acquired != lastAcquisition) {
  lastAcquisition = acquired;
  const Eigen::Vector3d acc = imu->getLinearAcceleration(); // IMU frame, m/s^2
  const Eigen::Vector3d gyro = imu->getAngularVelocity();   // IMU frame, rad/s
  const double delivered = imu->getDeliveryTimeStamp();   // simulation seconds
  // Consume acc/gyro with their acquisition timestamp, not the current world time.
}
With MANUAL, RaiSim leaves the measurements unchanged. User code can write hardware data with setLinearAcceleration(), setAngularVelocity() and setOrientation(), and manage its timestamps through setUpdateTimeStamp().
How the ideal reading is computed
The IMU uses the completed physics step's pose and angular velocity. Generalized acceleration is obtained from the solver's velocity change over a physics step of duration
A forward acceleration pass through the joint tree adds joint motion, rotational and Coriolis terms. For an IMU at world-frame offset
The last two terms account for tangential and centripetal acceleration. A sensor away from a rotation axis therefore measures acceleration even when the body's reference point is stationary.
Let
For an aligned, upright sensor with gravity
Ideal accelerometer checks
| Motion | Expected reading |
|---|---|
| Stationary and supported | |
| Free fall without rotation | |
| Constant rotation about +Z, zero gravity, sensor 0.1 m along the body's +X axis, |
Rotating the sensor mount rotates these vectors into the sensor frame. The accelerometer is not a gravity-removed linear-acceleration output.
getOrientation() and getGroundTruthOrientation() return the same ground-truth sensor-to-world quaternion in (w, x, y, z) order. It belongs to the delivered sample's acquisition time, including when delivery is delayed. It is not an attitude estimate derived from noisy accelerometer and gyro data; adding channel noise does not make this quaternion noisy. Validate an attitude estimator using the raw accelerometer and gyro channels instead.
Sampling and delivery
Acquisitions follow the step-counted grid of Update timing: when a deadline falls between physics steps, acquisition takes place at the first completed step at or after it, and the next deadline keeps the grid's phase rather than following the rounded acquisition time. There is at most one acquisition per physics step, so a requested rate above the physics rate cannot create additional motion data.
For a simulation starting at time zero with 1 ms physics, a 400 Hz IMU and 3 ms latency, the first samples are:
Simulation times in milliseconds
| Acquisition | Delivery |
|---|---|
| 1 | 4 |
| 4 | 7 |
| 6 | 9 |
| 9 | 12 |
| 11 | 14 |
The acquisition intervals alternate between 2 ms and 3 ms. The mean rate remains 400 Hz. getUpdateTimeStamp() is the acquisition time of the most recently delivered sample. getDeliveryTimeStamp() is when that sample became available. Both are simulation times, not wall-clock times.
For latency
Queue storage grows with acquired samples, up to 65,536 pending measurements (about 6.5 MiB per IMU). If this capacity is exhausted, or growth cannot allocate memory, new samples are dropped until room becomes available. Existing queued samples keep their acquisition times and delivery latency. A warning is emitted on the first loss after reset(); getDroppedMeasurementCount() reports the cumulative loss and is preserved by checkpoints. Reduce latency or update rate if this count is nonzero. The physics timestep continues normally.
Sleeping and fixed bodies continue to produce samples, including specific force from gravity and the configured stochastic errors. With filtering enabled, the filter advances every physics step, even when no new output sample is due.
Python RGB, LiDAR and IMU getProperties() return independent copies. Edit the copy and call setProperties() to validate and apply it; a rejected edit leaves the sensor unchanged. Depth retains mutable properties and requires updateRayDirections() after edits.
Configuring the sensor model
Accelerometer and gyro settings are independent. Prefer const access when copying properties, then apply the complete configuration with setProperties():
#include <utility> // std::as_const

auto properties = std::as_const(*imu).getProperties();
properties.seed = 43;
properties.accelerometer.bias = Eigen::Vector3d(0.01, -0.02, 0.03);
properties.accelerometer.noiseDensity = 0.002;
properties.accelerometer.biasRandomWalk = 0.0001;
properties.accelerometer.cutoffFrequency = 30.0;
properties.accelerometer.resolution = 0.001;
properties.gyroscope.bias = Eigen::Vector3d(0.001, -0.002, 0.003);
properties.gyroscope.noiseDensity = 0.0002;
properties.gyroscope.biasRandomWalk = 0.00001;
properties.gyroscope.cutoffFrequency = 50.0;
properties.gyroscope.resolution = 0.0001;
properties.maxAcc = 16.0 * 9.81; // 16 g, independently on each axis
properties.maxAngVel = 34.906585; // approximately 2000 degrees/s, in rad/s
properties.latency = 0.003;
imu->setProperties(properties);
imu->setUpdateRate(400.0);
These are illustrative settings, not a calibrated preset for a specific device. In the table below, a "channel unit" is m/s² for the accelerometer and rad/s for the gyro. All channel error settings default to zero (disabled).
Model parameters
| Property | Unit | Meaning |
|---|---|---|
bias | Channel units, three axes | Initial offset in sensor coordinates. |
noiseDensity | Channel units / sqrt(Hz) | Continuous white-noise strength; not the per-sample standard deviation. |
biasRandomWalk | Channel units / sqrt(s) | Strength of the Brownian bias increments. |
cutoffFrequency | Hz | First-order low-pass cutoff; zero bypasses filtering. |
resolution | Channel units | Quantization step; zero disables quantization. |
maxAcc, maxAngVel | m/s², rad/s | Positive symmetric per-axis clipping ranges. Defaults are effectively unlimited. |
latency | Seconds | Delay between acquisition and availability, from 0 to 60 seconds, shared by all reported channels. |
seed | Unsigned 32-bit integer | Zero derives a stream from sensor identity; nonzero selects an explicit stream. The World environment seed is mixed into both. |
Bias and unfiltered noise
For each axis, the initial bias is the configured bias. With bias random-walk strength
Bias is stepped at physics rate for filtered channels and at acquisition times for unfiltered channels, using the corresponding elapsed time. Its uncertainty grows with elapsed time; it is not independent additive noise at each sample. getAccelerometerBias() and getGyroscopeBias() expose the current simulated bias state for diagnostics. Those diagnostic states are not delayed to match a previously acquired measurement.
When cutoffFrequency is zero, the ideal signal is sampled at acquisition and the output before quantization/clipping is
where noiseDensity and
For example, noise density 0.002 m/s²/sqrt(Hz) at a uniform 400 Hz acquisition rate gives a sample standard deviation of 0.04 m/s² without the explicit filter. With rounded acquisition intervals, the variance follows each actual interval. Accelerometer and gyro axes use independent random draws, with separate channel parameters.
Low-pass filtering and filtered noise
For a positive cutoff
This is the exact first-order response for a held input over the step. The signal filter initializes from the first input to avoid an artificial startup transient. White noise passing through the same bandwidth is advanced separately:
The filtered reading is
Filtering advances before output downsampling. Coefficients are cached for a constant physics timestep and recomputed when the step changes. "Exact" here refers to these filter transitions; the simulated motion and stepped bias remain limited by the physics resolution and the held-input assumption.
Quantization and saturation
At acquisition, each output axis is quantized to step
With resolution=0, the rounding stage is skipped. maxAcc and maxAngVel are axis limits, so saturation on one axis does not reduce another axis. This replaces the previous vector-norm scaling behavior.
The legacy noiseType, mean and std settings now add output sample noise to both channels after the explicit filter and before quantization. Uniform noise has half-width sqrt(3) * std. Prefer the independent channel noise densities for new models; configuring both mechanisms adds both noise contributions.
Reset, replay and XML
setProperties() rejects invalid model parameters before applying them and resets measurements, bias, filters, sampling clock, pending delivery queue and random stream. Sensor name and full_name are immutable after construction; changing them through setProperties() is rejected. resetNoise() restarts only the random stream, preserving measurements and model history. reset() restarts the current model from its configured biases and seed; it does not rewind the robot or an application controller. Legacy mutable getProperties() access is supported: valid edits reset the model on the next update. Invalid edits, including identity changes, restore the last valid configuration and emit a warning, so they cannot interrupt a world step. Use setProperties() for immediate validation and exceptions before stepping. Obtaining a mutable reference permanently enables property comparisons on each update, even when it was obtained only to copy the settings. References remain tracked after checkpoint restore. Prefer std::as_const(*imu).getProperties() for reading, or call through a const reference.
Repeated motion with the same seed on the same platform/build reproduces the stochastic output. Cross-platform floating-point results need not be bit-identical. The IMU uses the same full-width seeded stream and Gaussian sampler as the camera/LiDAR models, so high seed bits also select different streams. World checkpoints preserve the complete random state, bias, filter state, acquisition clock, pending delayed samples and delivery timestamps. For replay of a running simulation, restore a world checkpoint rather than merely reapplying the same seed. Application controller and random state still belong to the application.
URDF declarations support the same configuration:
<sensor name="imu" type="imu" update_rate="400" seed="43" latency="0.003">
  <origin xyz="0.1 0 0" rpy="0 0 0"/>
  <limit acc_limit="156.96" ang_vel_limit="34.906585"/>
  <accelerometer bias="0.01 -0.02 0.03" noise_density="0.002"
                 bias_random_walk="0.0001" cutoff_frequency="30" resolution="0.001"/>
  <gyroscope bias="0.001 -0.002 0.003" noise_density="0.0002"
             bias_random_walk="0.00001" cutoff_frequency="50" resolution="0.0001"/>
</sensor>
Use the channel child elements above as the canonical URDF form. Prefixed acc_*/gyro_* attributes remain accepted for serialized world XML; avoid mixing those attributes with child elements in authored URDF. Legacy additive sample noise can be configured with a <noise type="gaussian" mean="0" stddev="0.01"/> child.
World XML export preserves this configuration, not the evolving stochastic state. The model fields require matching RaiSim headers and binaries that provide InertialMeasurementUnit::ChannelProperties; older binary packages do not implement this API.
Accuracy and performance limits
- Contact impulses contribute acceleration averaged over one physics step. Smaller timesteps may be required to resolve short impacts or vibration.
- A first-order filter is a configurable sensor approximation. There is no device-specific transfer function, temperature dependence, scale-factor error, cross-axis calibration error or attitude-estimation algorithm in this model.
- Delivery occurs only on physics steps. There is no wall-clock scheduling jitter or packet-loss model.
- The ideal path bypasses random draws and filtering. The zero-latency path needs no delay buffer; positive latency uses reusable queue storage. Acceleration is propagated once per articulated system when needed by its IMUs, without the inverse-dynamics force sweep.
For engine-side timing, the imu_sensor_benchmark target compares baseline integration, ideal IMUs and the full model on one thread: build-benchmark/benchmark/imu_sensor_benchmark --steps=500000 --robots=16.
CPU depth camera fallback
Prefer rayrai sensor rendering for RGB/depth observations when rayrai is available. World::captureDepthCamera is a world-level CPU depth camera for deterministic headless fallback and ray-query validation. It does not require a robot-mounted sensor, renderer, or visualizer. It casts one ray per pixel and can return:
- depth image as
std::vector<float> - object segmentation ids as
std::vector<int> - optional world-frame hit points
- capture timestamp from
World::getWorldTime() - optional deterministic Gaussian or uniform depth noise
The segmentation value is the hit object's getIndexInWorld(). Background is -1. Depth and points are NaN for background pixels.
The camera frame follows the same convention as RaiSim depth sensors: +X is forward, +Y is left, and +Z is up. The rotation passed to captureDepthCamera maps camera-frame vectors into the world frame.
CPU fallback scene and capture setup:
raisim::World world;
world.setWorldTime(1.25);
world.addGround(0.0);
auto* sphere = world.addSphere(0.5, 1.0);
sphere->setPosition(0.0, 0.0, 0.5);

raisim::World::DepthCameraProperties prop;
prop.width = 64;
prop.height = 48;
prop.clipNear = 0.01;
prop.clipFar = 10.0;
prop.hFOV = M_PI / 2.0;
prop.captureDepth = true;
prop.captureSegmentation = true;
prop.capturePoints = true;

// Camera at z=2 looking down. Columns are camera axes in world frame:
// camera +X -> world -Z, camera +Y -> world +Y, camera +Z -> world +X.
raisim::Mat<3, 3> R_WC;
R_WC.setZero();
R_WC(0, 2) = 1.0;
R_WC(1, 1) = 1.0;
R_WC(2, 0) = -1.0;

raisim::World::DepthCameraFrame frame;
world.captureDepthCamera({0.0, 0.0, 2.0}, R_WC, prop, frame);
Depth image
Enable captureDepth and read frame.depth. The vector has frame.width * frame.height entries in row-major order. Each value is the distance along the camera forward axis, not the Euclidean ray length. Pixels with no hit or hits outside [clipNear, clipFar] are NaN.
const int center = (prop.height / 2) * prop.width + (prop.width / 2);
if (std::isfinite(frame.depth[center])) {
  float centerDepthMeters = frame.depth[center];
}
Segmentation object id
Enable captureSegmentation and read frame.segmentation. A valid pixel stores the hit object's getIndexInWorld(). Background pixels store -1. You can compare this value to object ids kept by the application.
prop.captureSegmentation = true;
raisim::World::DepthCameraFrame frame;
world.captureDepthCamera(cameraPos, cameraRot, prop, frame);

const int center = (frame.height / 2) * frame.width + (frame.width / 2);
int objectId = frame.segmentation[center];
if (objectId == static_cast<int>(sphere->getIndexInWorld())) {
  // The center pixel hit the sphere.
}
Optional hit point per pixel
Set capturePoints to true to fill frame.points. Each entry is the world-frame hit point for the corresponding pixel. This is optional because it uses more memory than depth-only or segmentation-only capture.
prop.capturePoints = true;
raisim::World::DepthCameraFrame frame;
world.captureDepthCamera(cameraPos, cameraRot, prop, frame);

const int center = (frame.height / 2) * frame.width + (frame.width / 2);
const raisim::Vec<3>& hitPointW = frame.points[center];
if (std::isfinite(hitPointW[0])) {
  std::cout << "hit point in world: "
            << hitPointW[0] << ", "
            << hitPointW[1] << ", "
            << hitPointW[2] << std::endl;
}
Timestamp
Each frame stores the current World time in frame.timeStamp. This is useful when camera captures are interleaved with control, logging, or dataset generation.
world.setWorldTime(1.25);

raisim::World::DepthCameraFrame frame;
world.captureDepthCamera(cameraPos, cameraRot, prop, frame);

double captureTimeSeconds = frame.timeStamp;  // 1.25 in this example.
Optional deterministic depth noise
Depth noise is disabled by default.
This legacy world-level capture API is separate from the attached Sensor noise above. In this API, uniform depthNoiseStd is the half-range, while attached DepthCamera::DepthCameraProperties::std is a standard deviation (uniform half-range sqrt(3) * std). Its generator is reseeded on each capture: repeat captures with the same input repeat the noise, rather than advancing an attached sensor's stream. The legacy standard-library distributions reproduce within a platform/build; their Gaussian samples can differ between C++ standard libraries. Use attached depth sensors for the shared model, quantization, dropout, environment seeds and an advancing stream.
To enable it, set depthNoiseType, depthNoiseMean, depthNoiseStd, and depthNoiseSeed. The same world state, camera pose, properties, and seed produce the same noisy depth image.
prop.depthNoiseType =
    raisim::World::DepthCameraProperties::DepthNoiseType::GAUSSIAN;
prop.depthNoiseMean = 0.0;
prop.depthNoiseStd = 0.002;
prop.depthNoiseSeed = 42;

raisim::World::DepthCameraFrame noisyA;
raisim::World::DepthCameraFrame noisyB;
world.captureDepthCamera(cameraPos, cameraRot, prop, noisyA);
world.captureDepthCamera(cameraPos, cameraRot, prop, noisyB);

const int center = (prop.height / 2) * prop.width + (prop.width / 2);
assert(noisyA.depth[center] == noisyB.depth[center]);
Use DepthNoiseType::UNIFORM for bounded uniform noise in [mean - std, mean + std].
Self-filtering uses the same objectId and localId convention as rayTest. This is useful for cameras mounted on a robot:
world.captureDepthCamera(cameraPos,
                         cameraRot,
                         prop,
                         frame,
                         robot->getIndexInWorld(),
                         cameraParentLocalBodyId);
Using sensors with rayrai
rayrai can render RaiSim camera sensors in process. This is the recommended RGB/depth sensor path when rayrai is available because it uses the same sensor pose and intrinsics while producing renderer-backed color and depth buffers. Use the CPU camera capture API only when rayrai is unavailable or when a CPU-only deterministic ray-query result is specifically required.
Current runnable coverage:
- Rayrai RGB camera uses the Go1
d455_front/colorRGB sensor and renders it throughraisin::Camera. - Rayrai depth camera uses the Go1
d455_front/depthdepth sensor, renders the linear depth plane, reads afloatdepth buffer back to the CPU, and draws the projected points as instanced cubes. - Rayrai LiDAR point cloud shows a robot-mounted
SpinningLidarand visualizes its scan as a rayrai point cloud. - Rayrai segmentation camera renders a color image and a segmentation image from one camera and shows them side by side, colored by semantic class or by object.
- Rayrai ArUco marker covers marker rendering and camera-facing visual output.
Use the package examples above as public reference programs for sensor rendering workflows.
A typical RGB/depth setup has four parts: load a URDF with sensors, switch the camera sensors to manual measurements, create rayrai camera objects from those sensors, and render the sensor views every frame.
auto world = std::make_shared<raisim::World>();
world->addGround();

std::vector<std::string> modules = {"d455"};
auto* robot = world->addArticulatedSystem(go1Urdf, modules, go1ResourceDir);

auto* rgbCam = robot->getSensorSet("d455_front")
               ->getSensor<raisim::RGBCamera>("color");
auto* depthCam = robot->getSensorSet("d455_front")
                 ->getSensor<raisim::DepthCamera>("depth");

rgbCam->setMeasurementSource(raisim::Sensor::MeasurementSource::MANUAL);
depthCam->setMeasurementSource(raisim::Sensor::MeasurementSource::MANUAL);

auto viewer = std::make_shared<raisin::RayraiWindow>(world, 1280, 720);
auto rgbCamera = std::make_shared<raisin::Camera>(*rgbCam);
auto depthCamera = std::make_shared<raisin::Camera>(*depthCam);

const auto& rgbProp = rgbCam->getProperties();
const int rgbWidth = std::max(1, rgbProp.width);
const int rgbHeight = std::max(1, rgbProp.height);
std::vector<char> rgbBuffer(size_t(rgbWidth) * size_t(rgbHeight) * 4);

const auto& depthProp = depthCam->getProperties();
const int depthWidth = std::max(1, depthProp.width);
const int depthHeight = std::max(1, depthProp.height);
std::vector<float> depthBuffer(size_t(depthWidth) * size_t(depthHeight));

while (running) {
  world->integrate();

  viewer->renderWithExternalCamera(*rgbCam, *rgbCamera, {});
  viewer->renderWithExternalCamera(*depthCam, *depthCamera, {});
  viewer->renderDepthPlaneDistance(*depthCam, *depthCamera);

  rgbCamera->getRawImage(*rgbCam,
                         raisin::Camera::SensorStorageMode::CUSTOM_BUFFER,
                         rgbBuffer.data(),
                         rgbBuffer.size(),
                         /*flipVertical=*/false);
  depthCamera->getRawImage(*depthCam,
                           raisin::Camera::SensorStorageMode::CUSTOM_BUFFER,
                           depthBuffer.data(),
                           depthBuffer.size(),
                           /*flipVertical=*/false);
}
renderWithExternalCamera renders from the sensor pose; the raisin::Camera constructed from the sensor carries its intrinsics and resolution. renderDepthPlaneDistance converts the depth camera render into a linear plane-distance texture and the float readback buffer contains one depth value per pixel. The RGB readback buffer contains four bytes per pixel in BGRA order.
For LiDAR, rayrai_lidar_pointcloud computes the scan of the robot-mounted SpinningLidar on the CPU with update(world), transforms the sensor-frame points to world coordinates and displays them as a rayrai point cloud. To measure the scan on the GPU instead, call measureSpinningLidarSingleDrawGPU, which casts the same rays against the same collision geometry and stores the same sensor-frame points in the LiDAR with setScan():
auto* lidar = robot->getSensorSet("livox_lidar_0")
              ->getSensor<raisim::SpinningLidar>("lidar");

lidar->updatePose();
// toGlm(): small conversion helper defined in rayrai_lidar_pointcloud.cpp
const glm::dvec3 posW = toGlm(lidar->getPosition());
const glm::dmat3 rotW = toGlm(lidar->getOrientation());
viewer->measureSpinningLidarSingleDrawGPU(*lidar, posW, rotW);
Examples
- Use the dedicated rayrai RGB, depth, segmentation, LiDAR, and ArUco examples above for robot-attached rendered sensor buffers.
- Use
rayrai_complete_showcasewhen you need one runnable scene that combines RGB/depth cameras, LiDAR visualization, and custom visuals. World::captureDepthCamerasupports depth, segmentation, optional hit points, and timestamps without a visualizer, but it is the CPU fallback path.
Parent Class API
Depth Camera API
Segmentation Camera API
RGB Camera API
Inertial Measurement Unit API
Force/torque and tactile sensors
ForceSensor is a six-axis joint load cell. Its force is the force exerted by the parent on the child subtree, expressed in the sensor frame. Its torque is about the sensor origin, also in the sensor frame. It includes gravity, inertial loads and contact loads. No setComputeInverseDynamics(true) setting is required.
Use type="force" (or force_torque) in a link's sensor XML. The incoming joint of that original link is selected automatically; joint="wrist_joint" selects an explicit joint. Fixed-joint boundaries preserve the original child subtree when the loader merges fixed bodies. Sensor position and orientation determine the measurement frame and moment origin; they do not change the selected boundary. For a sensor added programmatically after robot construction, an empty joint selects its attachment's moving parent subtree. Reattaching it to another moving parent updates that implicit selection. Set joint explicitly to keep the boundary independent of reattachment.
<sensor name="wrist_load" type="force" update_rate="500">
  <origin xyz="0 0 0.03" rpy="0 0 0"/>
</sensor>
TactileSensor aggregates external contact forces over a rectangular pad and a row-major grid of sensing elements (taxels). Its +X axis points out of the pad; +Y spans its width and +Z its height. Contact force on a loaded pad has a negative X component. getNormalForce() reports positive compressive load. Only contacts within the pad's width, height and distance depth on either side of its surface plane contribute. The pad observes the owning original link's collision geometries. Optional collision matches a declared URDF collision name or its generated link/index alias. It selects every matching geometry on that original link, including duplicate names or overlapping aliases. Generated names remain available to existing APIs. A programmatically attached pad with an empty link observes its moving parent body. The pad must have matching collision geometry.
<sensor name="finger_pad" type="tactile" update_rate="500"
        width="0.04" height="0.03" depth="0.005" columns="8" rows="6">
  <origin xyz="0.01 0 0" rpy="0 0 0"/>
</sensor>auto* force = robot->getSensorSet("wrist")->getSensor<raisim::ForceSensor>("wrist_load");
auto* pad = robot->getSensorSet("finger")->getSensor<raisim::TactileSensor>("finger_pad");
world.integrate();
const auto& wrenchForce = force->getForce(); // N, in the sensor frame
const auto& wrenchTorque = force->getTorque(); // Nm, about the sensor origin
const auto& taxels = pad->getTaxelForces(); // rows * columns sensor-frame force vectors, N
if (pad->hasCenterOfPressure()) {
const auto& yz = pad->getCenterOfPressure(); // Y/Z coordinates in metres
}
const auto& slip = pad->getTaxelSlipVelocities(); // load-weighted Y/Z surface velocity, m/sHeaders are raisim/sensors/ForceSensor.hpp and raisim/sensors/TactileSensor.hpp. Python exposes the same classes, properties and measurement methods. getTaxelForces() returns a copied (rows * columns, 3) NumPy array; getTaxelSlipVelocities() returns (rows * columns, 2).
Both sensors collect after the final contact solve, before position integration. They average impulses over the actual acquisition interval and include every physics step and deformable substep. The first sample covers the first completed step. Later acquisitions follow a phase-preserving clock, with at most one sample per completed physics substep; requesting a higher rate does not fabricate additional samples. getAcquisitionStartTime() and getUpdateTimeStamp() delimit the delivered sample's interval; getDeliveryTimeStamp() gives its availability. Clocks stay negative until a sample is delivered. Moving world time away from the last collected physics time resets acquisition history before the next collection or explicit update(), including forward jumps and rewinds. Repeated updates at the current physics time preserve the last reading. Checkpoints preserve the full history for exact replay.
Changing the registered attachment frame or its fixed offset/orientation clears accumulation, filtering and queued measurements before the next collection or explicit update(). The delivered timestamp returns to its negative initial state until a new sample arrives. The sensor noise stream continues across a remount; ordinary robot motion leaves acquisition history intact. Checkpoints preserve the attachment signature with the measurement history, including a checkpoint taken after reattachment but before the next update.
The optional model properties apply bias, Gaussian sample noise, first-order bandwidth, per-axis force/torque saturation and latency to the six net wrench channels. XML names are force_bias, torque_bias, force_noise_std, torque_noise_std, cutoff_frequency, max_force, max_torque, latency and seed. All effects are disabled by default. Taxel readings, center of pressure and slip remain ideal contact diagnostics. With a noisy or saturated net wrench, the sum of the ideal grid need not equal that wrench.
Latency is between 0 and 60 seconds. Queue storage grows on demand and retains at most 1,048,576 channel values. Overflow drops new samples, reports a warning and increments getDroppedMeasurementCount(). reset() clears measurements, accumulators, filters, pending deliveries and random state; resetNoise() only restarts the random stream. World reseeding and checkpoint restoration include both sensor types. World XML export/import preserves their configuration.
Active physics-backed load sensors keep their contact islands awake so a resting grasp continues to report its load. The physics implementation is single-threaded and needs no renderer. The TCP viewer displays net wrenches and tactile grids in the selected robot's Sensors tab.
The grid reports contact forces in newtons, not a calibrated elastomer pressure field. Its spatial detail is limited by the solver's contact manifold; increasing grid resolution does not create additional contact information.
For a fixed-joint cut inside a merged body, changing the merged body's inertia loses the individual link mass distribution. Such edits are rejected during measurement. Likewise, a direct body-level force or constraint on that partially selected merged body has no original-link identity and is rejected. Apply those loads to a distinct moving body below the sensor. External contact loads retain their original collision-link identity and are supported across fixed cuts.
Run testWrenchSensors for analytical-load, contact, sampling, XML and replay tests. wrench_sensor_benchmark --steps 100000 --pads 1 --grid 8 measures complete integration with sensing. Compare --disabled, --force-only, larger --grid values and --pads 16 to measure overhead and scaling; run benchmarks on one thread.
The force_tactile_sensors example supports --steps=5000, an explicit --activation-key=/path/to/activation.raisim, and --server for the TCP viewer. A 2 kg sphere rests on a 1 kg instrumented pad: its tactile load is 19.62 N and the mounting load is 29.43 N. After one second a lateral force produces motion.
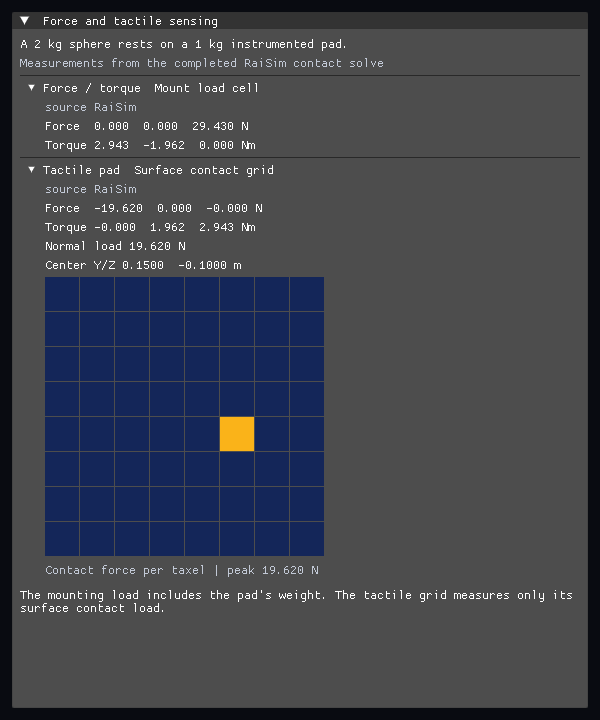
The showcase uses actual measurements from a 2 kg sphere on a 1 kg pad. Regenerate it from a source build with:
./build-benchmark/visualizer/rayrai/rayrai_tcp_viewer_test --wrench-showcase /tmp/force_tactile.png /path/to/activation.raisimRigid, deformable and granular surface contacts contribute to the readings. Granular contact forces retain their collision-geometry identity even across a merged fixed-joint cut. Fluid loading is included in joint reactions, including fixed mounts.
Invalid joint names, missing sensing geometry, geometry on a different moving body, and unsupported merged-body load assignments are rejected before integration advances. Correcting the configuration leaves the world usable, including checkpoints and substepping. Change sensor configuration between complete integration steps. Changing pad dimensions or restoring a checkpoint refreshes the connected viewer sensor description automatically.
Net torque includes rolling/spinning friction couples on fixed sensing geometry. A pure couple has no unique distribution over point-force taxels, so reconstructing torque from taxel forces alone can differ from the net torque channel. For rigid solver contacts, dynamic articulated bodies do not currently support rolling/spinning angular impulses; sensor readings follow the loads that model actually applies. Granular contact torques are applied as external loads and remain included for moving pads.
Activate new sensors between complete integration steps so their contact islands wake and granular contact metadata is captured. A valid pad resize on an already instrumented system between integrate1() and integrate2() rebinds before collection, and disabling a sensor to MANUAL stops that acquisition.
The TCP protocol negotiates support for load sensors. Older viewers still receive the physics scene and their supported sensor types; use an updated viewer for the wrench and tactile panels.
Add --granular to wrench_sensor_benchmark to measure granular contact sensing.
A single-threaded Linux x86 benchmark on a Ryzen 9 3950X, using a Clang 20.1.8 Release build, measured these medians over three serial runs pinned to one CPU. Times cover the complete integration step, including contact solving and sensor collection, in microseconds. Python grid copies and viewer serialization are outside the timed interval. The comparison isolates attachment-history checks, sparse delayed snapshots, and single-pass external-load routing.
| Scene | Before | After |
|---|---|---|
| One pad, 8 x 8, one rigid contact | 1.42 | 1.38 |
| One pad, 64 x 64, one rigid contact | 1.40 | 1.39 |
| One pad, 64 x 64, 20 ms sensor latency | 9.33 | 1.55 |
| 32 links, 256 external loads, 8 force sensors | 86.98 | 88.17 |
| 64 links, 512 external loads, 16 force sensors | 466.36 | 224.46 |
| 64 links, 512 external loads, sensors disabled | 137.84 | 153.34 |
| One pad, 2 x 2, 64 contacts, 20 ms latency | 43.33 | 48.90 |
Runs shared the host with other work; the disabled control also changed, so smaller timing differences are inconclusive. The large reductions in delayed sparse-grid work and heavily loaded sensor chains remain visible. That benchmark matrix has 46 configurations, including disabled controls, force-only and tactile-only cases, sampling rates, latency, scene clutter, contacts, grids, multiple pads and multiple joint sensors. The benchmark checks finite readings and the expected supported load once a measurement has been delivered.
Both sensor types are active in pad rows. Force-only chain rows attach one load cell at each of the first specified links. Root mounting loads are 333.54 N for 32 links, 647.46 N for 64 links, and 29.43 N for one link. External benchmark loads act transversely to the joints and do not change these vertical loads.
The immediate tactile path averages and clears touched taxels only. Each taxel uses three force channels and two load-weighted slip channels; its normal weight comes from the ideal negative X force. Delayed snapshots contain active taxels when that representation is smaller, and retain dense storage for dense samples. This storage change preserves the dense-grid-based queue capacity and drop policy. Resetting or resizing a pad clears queued samples before its cell layout changes. Grid serialization and Python copies still scale with the full grid.
Force acquisition sums inertial/fluid loads per selected body and traverses each external force, constraint load, pin endpoint and spatial tendon site once per sensor. Body membership selects the appropriate subtree; ambiguous loads on a partially selected merged body remain rejected.
The benchmark supports --surfaces N to place multiple pads on separate fixed links of one articulated system. Use --no-contact to isolate validation and idle collection, and compare --disabled with --tactile-only. Matching geometry is validated using a retained index that rechecks live ownership and names on every step and rescans when the match changes. Checkpoints preserve the index.
The benchmark supports --tactile-only, --force-only, --disabled, --rate, --latency, --links, --contacts, --background, --loads, --force-cells, and --dt, plus --epoch (nonnegative initial world time), in addition to --pads, --grid, --steps, and --granular. --loads requires at least two links; --force-cells must not exceed the link count. For many small grains, use a suitable physical time step: the 64-grain comparison uses --dt 0.0001. Examples:
./build-benchmark/benchmark/wrench_sensor_benchmark --grid 64 --latency 0.02 --steps 15000
./build-benchmark/benchmark/wrench_sensor_benchmark --links 64 --loads 512 --force-cells 16 --force-only --steps 500
./build-benchmark/benchmark/wrench_sensor_benchmark --granular --contacts 64 --dt 0.0001 --steps 4000
A further geometry-validation audit measured the workloads below in a Clang 20 Release build. Values are medians of three serial repetitions pinned to one CPU, in microseconds per complete physics step. The 30-case matrix also checks loaded force chains, sparse and dense grids, sampling rates, latency and granular loads.
| Pads on one articulated system | Before | After |
|---|---|---|
| 64 idle pads, 1 x 1 grids | 15.63 | 9.22 |
| 256 idle pads, 1 x 1 grids | 123.18 | 39.26 |
| Same 256 geometries, sensors disabled | 10.58 | 10.68 |
| 64 loaded pads, 1 x 1 grids | 91.52 | 81.47 |
The retained geometry index removes repeated prefix scans while preserving validation against live body ownership and both collision-name forms. It is an existence hint; each contact still checks every applicable sensor's selector. The disabled control changed by about 1%, whereas the idle 256-pad workload fell by 68%. Small timing differences in the other workloads remain host-dependent. Benchmark load, finite-value and grid-sum checks run outside the timed interval.
Regression coverage includes deformable-terrain row-impulse balance against joint and tactile forces/torques, grid sums and pressure center, with rotated scenes, both object orders, off-center external loads and checkpoint replay. Named-geometry tests cover fixed-link merging, XML reload, duplicate aliases, live ownership/name changes, recovery after rejected configurations and replay.
Load-sensor clock discontinuities are tracked independently of floating-point world-time magnitude. Even a small explicit clock edit at a large epoch clears old samples; changing time away and back also clears them. A missed collection while sensing is disabled starts a fresh interval when sensing resumes, including when all load sensors were disabled. Repeated reads, an unchanged-time setter, variable timesteps and normal deformable substeps preserve acquisition history. Checkpoint restoration restores the clock identity with the complete history. Finite positive update rates above the physics frequency remain capped to one new sample per physics substep, including rates near the floating-point maximum.
Contact collection uses sorted original-link groups to find the applicable pads. Programmatic pads with an empty link and all joint force sensors still receive each applicable contact once. Every callback retains the live body, original-link and collision-name checks. Changing link properties or active sensor membership rebuilds routing; checkpoints restore the routing with sensor properties. Rigid and granular contacts use the same routing rules.
That benchmark matrix has 46 configurations. Additional cases cover 256 loaded pads, many granular-contact pads, maximum finite update rates, large initial world times and delayed high-rate grids. Zero-latency samples requested at or above the physics frequency must carry the current completed-step timestamp; a finite but stale load therefore cannot pass validation. Examples:
./build-benchmark/benchmark/wrench_sensor_benchmark --surfaces 256 --grid 1 --tactile-only --steps 1000
./build-benchmark/benchmark/wrench_sensor_benchmark --rate 1.7976931348623157e308 --dt 2 --no-contact --force-only --steps 20000
./build-benchmark/benchmark/wrench_sensor_benchmark --epoch 1000000000 --no-contact --force-only --steps 20000
A contact-routing comparison used interleaved old/new runs on one CPU, three repetitions per binary and configuration, in a Clang 20 Release build. Times are medians in microseconds per complete physics step. Runs shared the host with other work; interleaving reduces timing drift but small differences remain inconclusive.
| Contact-routing workload | Before | After |
|---|---|---|
| 64 loaded pads, 1 x 1 grids | 126.56 | 82.77 |
| 256 loaded pads, 1 x 1 grids | 971.93 | 380.82 |
| 64 pads with granular contacts | 157.53 | 113.04 |
| 256 geometries without sensors (idle control) | 12.60 | 12.64 |
The 256-loaded-pad workload is about 2.6 times faster. Sensor sets of four or fewer retain direct dispatch, avoiding the index lookup for small sets. Larger sets rebuild the sorted routing only when active identities or link properties change. The property setter invalidates cached keys; ordinary idle steps do not repeat string-key comparisons. Regression tests cross the direct/indexed threshold in both directions and verify fresh samples after reactivation. That comparison covered 35 configurations; numerical-edge configurations verify maximum finite rates, large epochs and delayed large grids. Every timed run checks supported loads and grid consistency after timing.
The wrench measurement model preserves small loads after large transients and uses stable interpolation for opposite-sign loads and near-unit bandwidth coefficients. Ordinary representable values keep their physical units internally. If a finite bias/noise calculation exceeds the double range, an internal power-of-two exponent retains that intermediate until filtering brings it back into range. Output saturation still follows filtering. Exact cancellation of a large load and bias therefore retains a tiny noise term rather than erasing it through a fixed normalization. Checkpoints preserve the exponent with the filter and random state. Stable arithmetic can change the last bits of a filtered result; deterministic replay remains exact within the same platform and build.
Bandwidth coefficients retain finite cutoff-times-duration products, including extreme cutoffs with very short steps and representable subnormal products. The ideal path bypasses optional model arithmetic while retaining saturation. Rigid-body inertia rotation and gyroscopic terms are skipped only when angular velocity and acceleration are exactly zero; the rotated COM force moment and all fluid terms are retained.
When a larger physics step makes several delayed samples available together, only the newest due snapshot is decoded. This produces the same public reading, acquisition interval and availability time as delivering that due prefix in order. Earlier due entries are consumed without increasing the capacity-drop counter. The queue retains its existing memory bound and overflow policy. Wrapped, partially due and fully due queues share the same behavior for force and tactile sensors, including dense, sparse and empty tactile payloads.
The benchmark accepts --noise STD (force noise STD in N; torque noise STD is one tenth as large in Nm), --cutoff HZ, and --delivery-batch N. Sampling uses an explicit seed for repeatability. The delivery-batch workload alternates N fine steps with one step N times as long; it reports microseconds_per_burst as well as average step time. This workload supports rigid contacts; granular workloads retain their configured fixed step. Noise-aware load bounds and ideal grid/normal checks are evaluated outside timing. That numerical comparison has 61 configurations: 53 standard comparisons and eight numerical edge cases; the latest expanded matrix is described below.
./build-benchmark/benchmark/wrench_sensor_benchmark --grid 64 --latency 0.032 --delivery-batch 32 --steps 33000
./build-benchmark/benchmark/wrench_sensor_benchmark --noise 0.1 --cutoff 25 --steps 50000
The sensor suite contains 78 regressions. Added coverage includes runtime mass, COM and rotated anisotropic inertia edits checked against Newton-Euler balance, checkpoint replay, rejection/recovery for ambiguous partial fixed cuts, numerical signal extremes, tiny bias/noise residuals and overdue-frame delivery across variable steps and queue wrap. Queue replay is checked from checkpoints captured both before and after a batch becomes due.
The final Clang 20 Release comparison interleaved old/new binaries on one CPU, with three repetitions per configuration. Average complete-step time is shown separately from the coarse step that releases a delivery burst, in microseconds.
| Workload | Metric | Before | After |
|---|---|---|---|
| 64 links, 512 external loads, 16 joint sensors | Average step | 193.42 | 183.06 |
| Same loaded chain, sensors disabled | Average step | 136.29 | 137.32 |
| 16 pads, 64 x 64 grids, 32-sample delivery bursts | Burst step | 31.40 | 20.57 |
| Same 16-pad burst workload | Average step | 19.69 | 19.11 |
| One 8 x 8 pad, 64 contacts, delivery bursts | Burst step | 48.51 | 42.48 |
| One pad, noise STD 0.1 N and cutoff 25 Hz | Average step | 1.51 | 1.61 |
The 16-pad delivery spike fell by about 35%, and the heavily loaded joint-sensor chain improved by about 5%. The corrected noisy/filter arithmetic costs roughly 4-8% in the measured optional-model cases (around 0.1 microseconds for the small combined-sensor scene). Most ideal/control cases differ by only a few percent; the host was shared, so those small differences are inconclusive. The final 46-case matrix includes all load, grid, finite-value and freshness checks after timing, including noise-aware bounds where the net wrench is stochastic.
Joint boundary resolution uses linear passes through the original link preorder and body membership. Editing only the measurement model retains that boundary; changing the joint or the host of an implicit boundary resolves it again. The benchmark reports first_step_microseconds and reconfigure_step_microseconds in addition to steady-state timing. The latter measures the first step after reapplying force-sensor properties; it excludes the property setter itself.
./build-benchmark/benchmark/wrench_sensor_benchmark --force-only --no-contact --links 256 --force-cells 256 --steps 1000Representable tiny pin reactions are retained without squaring impulses for zero checks. Ambiguous external or constraint loads on a partial fixed-joint cut are rejected even at very small magnitudes. Invalid registered frame parents, nonfinite poses and improper rotations are rejected before physics advances. The attachment setter requires its supplied pose to match the registered frame; register a separate CoordinateFrame for a custom sensor offset. Tactile contact coordinates are checked before grid indexing, and rectangular bounds retain their meaning for subnormal positive dimensions. Regressions cover rejection and recovery, custom mounts, tiny pin/load reactions, both subnormal grid axes and mixed fixed/moving branches through model edits and checkpoint replay.
Fixed-cut inertia is accumulated about the selected center of mass, preserving small intrinsic terms at large offsets from the body origin. The large-offset regression covers 100 km and 100,000 km mounts and model-edit replay. Preflight frame validation leaves acquisition history intact when another sensor is invalid; repeated failures and successful repair are checked explicitly.
The preceding 49-case comparison interleaved three runs per binary on CPU 3, with one benchmark thread. Setup timing includes one complete integration step.
| Links / joint sensors | Metric | Before (us) | After (us) |
|---|---|---|---|
| 64 / 64 | First step | 783.05 | 507.91 |
| 64 / 64 | Reconfigured step | 410.95 | 67.82 |
| 64 / 64 | Steady step | 64.90 | 66.18 |
| 128 / 128 | First step | 3723.53 | 1737.82 |
| 128 / 128 | Reconfigured step | 2494.20 | 225.96 |
| 128 / 128 | Steady step | 223.70 | 226.22 |
| 256 / 256 | First step | 20409.19 | 7016.84 |
| 256 / 256 | Reconfigured step | 15856.34 | 836.73 |
| 256 / 256 | Steady step | 821.64 | 826.87 |
The validation checks add measurable cost in some many-pad workloads:
| Workload | Before (us/step) | After (us/step) |
|---|---|---|
| 64 idle pads | 8.91 | 9.96 |
| 256 idle pads | 38.03 | 42.11 |
| 64 loaded pads, granular contacts | 69.13 | 76.02 |
Finite/proper-pose checks reuse the exact validated attachment signature until the pose changes; frame and parent bounds are checked every time. The 256-idle-pad case adds 4.08 us per step (10.7%). Small differences in other steady-state workloads remain sensitive to this shared host. All 294 timed runs passed their load, grid and timestamp checks.
Acquisition now retains scaled per-channel integrals when a finite force times its duration, a contact moment, or a weighted tactile numerator would overflow or underflow. Normal inputs use a bounded ordinary-arithmetic path; the scaled buffer is allocated only when needed and its capacity is reused. Partial acquisitions, both arithmetic paths and their transition state are checkpointed. Granular loads carry their actual substep duration through contact routing, without first converting force to a potentially unrepresentable impulse. Tiny rolling couples use exact component checks in articulated-body dynamics.
Tactile pressure centers and slip are normalized by raw normal impulses before conversion to ordinary doubles and before queueing. This avoids overflowing an intermediate weighted numerator even when its final ratio is finite. Each active taxel needs two fewer divisions; local contact point/force vectors are reused when accumulating torque. Packed and dense queue layouts retain their size, and public measurements and wire units are unchanged.
Sampling uses a compensated phase countdown, and delayed samples use a private compensated physics clock. Both accumulate the specified physics steps rather than differences between rounded absolute world-clock tags. Floating-point allowances scale with the period/delay and cannot consume an entire requested period, step or positive delay. Public timestamps remain world-clock tags. A positive delay below the resolution of a large epoch still waits for physics progress. The queue uses one threshold per search, preserving its monotone due prefix and newest-due delivery behavior. Repeated subtraction, long latency, large epochs and coarse/fine step transitions are covered by release-step tests.
Fluid activation is checked once per joint-sensor preparation, and fluid scratch loads are constructed only when needed. Cached whole-body loads remain available when the current fluid configuration is inactive. Analytical buoyancy tests cover whole bodies and original fixed-link cuts through checkpoint replay.
The force/tactile numerical regressions include signed continuous-load extremes, tiny clock intervals, large epochs, delayed weighted-slip replay, subnormal rounding, granular substeps, tiny rolling couples checked against inverse dynamics, and transitions between ordinary and scaled accumulation.
The benchmark adds --gravity G and --explicit-updates for acquisition and delivery checks. Tiny supported loads are checked with relative bounds, and completed acquisitions and delayed readings are checked against the configured period and latency outside timing. --fluid-density RHO adds an ambient medium to force-only, no-contact, single-surface workloads with analytical buoyancy checks.
./build-benchmark/benchmark/wrench_sensor_benchmark --force-only --no-contact --gravity 1e-300 --dt 1e-30 --rate 1e30
./build-benchmark/benchmark/wrench_sensor_benchmark --force-only --no-contact --gravity 1e308 --dt 2
./build-benchmark/benchmark/wrench_sensor_benchmark --force-only --no-contact --epoch 1e12 --latency 1e-13 --explicit-updates
./build-benchmark/benchmark/wrench_sensor_benchmark --tactile-only --grid 1 --contacts 256
./build-benchmark/benchmark/wrench_sensor_benchmark --force-only --no-contact --fluid-density 1 --links 16 --force-cells 16
The earlier numerical comparison interleaved three old/new runs for 53 configurations on CPU 3 with one benchmark thread. Eight additional numerical configurations were run three times with the corrected library; their baseline outcome is recorded separately rather than treating invalid readings as performance measurements.
| Workload | Before (us/step) | After (us/step) |
|---|---|---|
| One joint force sensor | 1.27 | 1.30 |
| Joint sensor and 8 x 8 pad | 1.42 | 1.48 |
| 256 idle pads | 42.02 | 40.14 |
| 64 loaded granular pads | 72.00 | 78.23 |
| Joint sensor and 8 x 8 pad, 64 granular contacts | 12.45 | 14.17 |
| 256-link joint-sensor chain without fluid | 827.59 | 488.04 |
| 64 contacts on one taxel | 40.20 | 41.31 |
| 256 contacts on one taxel | 172.39 | 176.55 |
| One joint sensor with ambient fluid | 1.02 | 1.05 |
| 16-link sensor chain with ambient fluid | 10.01 | 9.89 |
All 342 comparison/current numerical runs passed their physical, grid and timestamp checks. The baseline failed correctness checks in 7 of the eight numerical cases. Small timing differences remain sensitive to the shared host; the table includes validation overhead as well as the arithmetic savings.
Joint load cells retain an immutable reference to the core's initialized merged mass, COM and central inertia. Partial fixed-link cuts reject any changed value, including nextafter-sized, subnormal and nonfinite edits, before the first acquisition or a later integration. Signed-zero edits are accepted, and restoring the original properties makes the cut usable again. Whole-body cuts continue to use live properties. A compact body/index list stores inertia caches only for partial cuts and skips unused recomposition during boundary setup. Inactive-fluid work is gated once per sensor; zero COM offsets skip rotation arithmetic, and rotation matrices for angular inertia are loaded only when needed.
Internal pin, tendon and self-contact forces cancel as pairs before being added to a small supported wrench. Real point-offset moments and applied angular impulses are retained. Tendon pairs use the solver's stored tangent gradients, including wrapping and pulley scaling. A tactile pad still measures the local contact even when both contact participants lie inside a joint sensor's cut.
integrateNoContactDetection() followed by integrate2() performs the same sensor preflight and acquisition lifecycle as ordinary stepping. It validates before changing the split-step state, collects fresh sensors and discards removed systems from the collection registry. Change sensor and fluid configuration between completed integration steps. Latency, source changes and checkpoint replay are covered on this path.
The force/tactile suite now has 78 regressions. New checks cover the no-contact lifecycle and removal crash, microscale and pre-acquisition property edits, rotated XML reload, large internal pins and tendons, wrapped/pulley paths, static and moving self-contacts, tactile loads and replay. Mutation checks confirm that disabling paired cancellation fails the wrapped-tendon and self-contact tests.
The benchmark adds --fixed-chain for original-link cuts inside merged bodies and --no-contact-detection for split stepping (requires --no-contact). --com-offset X (meters) checks offset moments, and --angular-speed W (rad/s) checks centripetal forces in rotating fixed chains. Both use --force-only --no-contact; rotation also requires --fixed-chain. --internal-tension T adds an internal multi-leg tendon preload in force-only, no-contact scenes. Partial merged cuts with a tendon are rejected.
./build-benchmark/benchmark/wrench_sensor_benchmark --fixed-chain --links 256 --force-cells 256 --force-only --no-contact --steps 5000
./build-benchmark/benchmark/wrench_sensor_benchmark --no-contact-detection --no-contact --grid 64 --latency 0.02 --steps 30000
./build-benchmark/benchmark/wrench_sensor_benchmark --internal-tension 1e12 --gravity 5e-8 --force-only --no-contact --steps 30000
./build-benchmark/benchmark/wrench_sensor_benchmark --fixed-chain --links 256 --force-cells 256 --com-offset 0.1 --angular-speed 3 --force-only --no-contact --steps 5000
The latest matrix has 80 configurations, run serially on CPU 3 with one benchmark thread. Values below are medians of three interleaved old/new Clang 20 Release runs, in microseconds. First-step timing includes integration and boundary setup. Physical, taxel and timestamp checks run outside timing.
| Workload | Metric | Before (us) | After (us) |
|---|---|---|---|
| One joint force sensor | Steady step | 1.31 | 1.29 |
| Joint sensor and 8 x 8 pad | Steady step | 1.49 | 1.47 |
| 64 links / 64 joint sensors | First step | 492.61 | 131.78 |
| 256 links / 256 joint sensors | First step | 6523.20 | 1320.38 |
| 256 links / 256 joint sensors | Steady step | 488.25 | 313.58 |
| 256-link chain, COM offset 0.1 m | Steady step | 488.64 | 350.63 |
| 256 merged fixed links / 256 cuts | First step | 1663.78 | 1054.52 |
| 256 merged fixed links / 256 cuts | Steady step | 38.04 | 38.02 |
| 256 idle pads | Steady step | 40.11 | 40.58 |
| Joint sensor and 8 x 8 pad, 64 granular contacts | Steady step | 14.00 | 14.14 |
| Internal tendon preload, ordinary gravity | Steady step | 1.05 | 1.03 |
| 256 original cuts on a rotating body | Steady step | 45.22 | 47.05 |
All 462 successful comparison/current runs passed their checks. The baseline failed correctness in 6 configurations: five active no-contact stepping cases and the tiny supported load under a large tendon preload. Invalid baseline readings are excluded from timing comparisons. Small timing differences remain sensitive to the shared host.
Rotating multi-cut workloads were 4–7% slower in this run. The disabled no-contact-detection control increased from 0.257 to 0.307 us/step with the required sensor-registry preflight. These costs are retained in the comparison.