
Rayrai Example: Depth Camera
Overview
Renders a linear depth texture from the Go1 depth camera and shows it in ImGui with a frustum overlay. The sensed points are projected back into the world and drawn as small instanced cubes. This is the recommended RGB/depth sensor path when rayrai is available. The active code path reads rendered depth from rayrai. The source also keeps a disabled (#if 0) World::captureDepthCamera block as a deterministic CPU fallback for headless ray-query use.
Screenshot
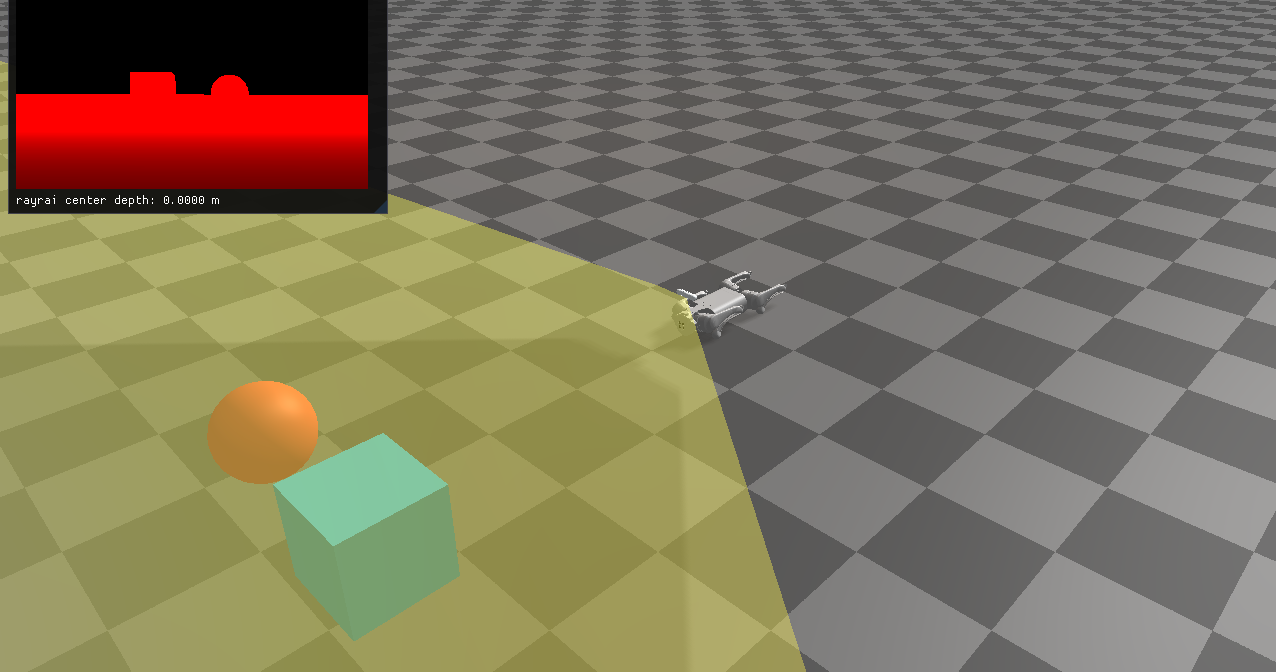
Target
CMake target: rayrai_depth_camera.
Run
Run the build-tree executable:
bash
./build-examples/examples/rayrai_depth_cameraOn Windows, run rayrai_depth_camera.exe instead. This example renders in process with rayrai and does not need rayrai_tcp_viewer.
Details
- Loads Go1 with the D455 module and fetches the depth sensor.
- Renders a linear depth texture and shows it in an ImGui window.
- Reads the rayrai depth buffer with
raisin::Camera::getRawImage, flipped so rows run top to bottom like the sensor's own pixel layout. - Projects the depth image into world-frame points with
DepthCamera::depthToPointCloudand draws every fourth pixel in each direction as a small cube in oneInstancedVisualsbatch, shaded from yellow (near) to blue (far). Pixels without a hit (depth 0) are skipped. The batch is not detectable, so the depth camera never sees its own points. - Keeps a disabled CPU
World::captureDepthCamerafallback that returns depth, a segmentation object id and an optional hit point per pixel, a timestamp, and deterministic depth noise when rayrai rendering is not available. - Places a sphere and a box in front of the camera using its pose.