
Server Example: Kinematic Platform
Overview
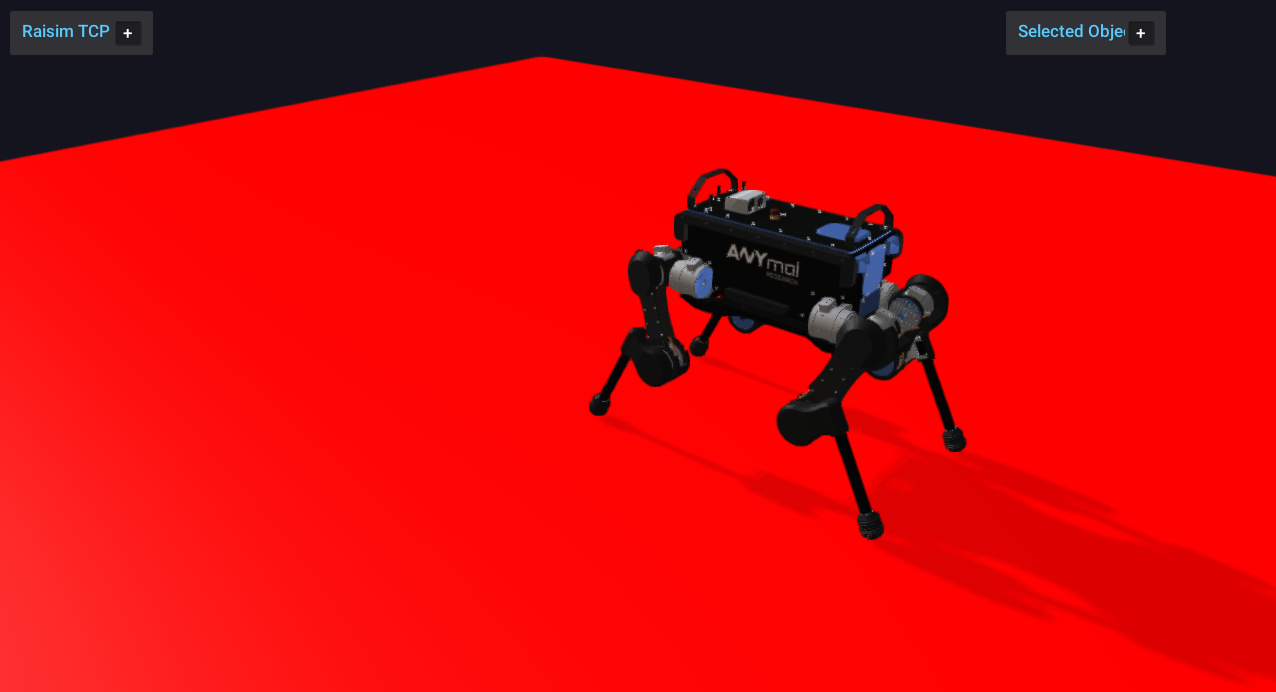
Creates a kinematic platform that moves up and down sinusoidally under an ANYmal. It demonstrates kinematic bodies and their interaction with dynamic robots.
Screenshot
Target
CMake target: kinematic_platform.
Run
Run the build-tree executable:
bash
./build-examples/examples/kinematic_platformOn Windows, run kinematic_platform.exe instead. This example uses RaisimServer. Start rayrai_tcp_viewer and connect to port 8080.
Details
- Creates a 10 m × 10 m kinematic box (infinite mass) as the ground and sets a sinusoidal vertical velocity on it every step.
- Places an ANYmal on top with PD posture control.
- Demonstrates
BodyType::KINEMATICand prescribed motion.