
Server Example: Minitaur PD
Overview
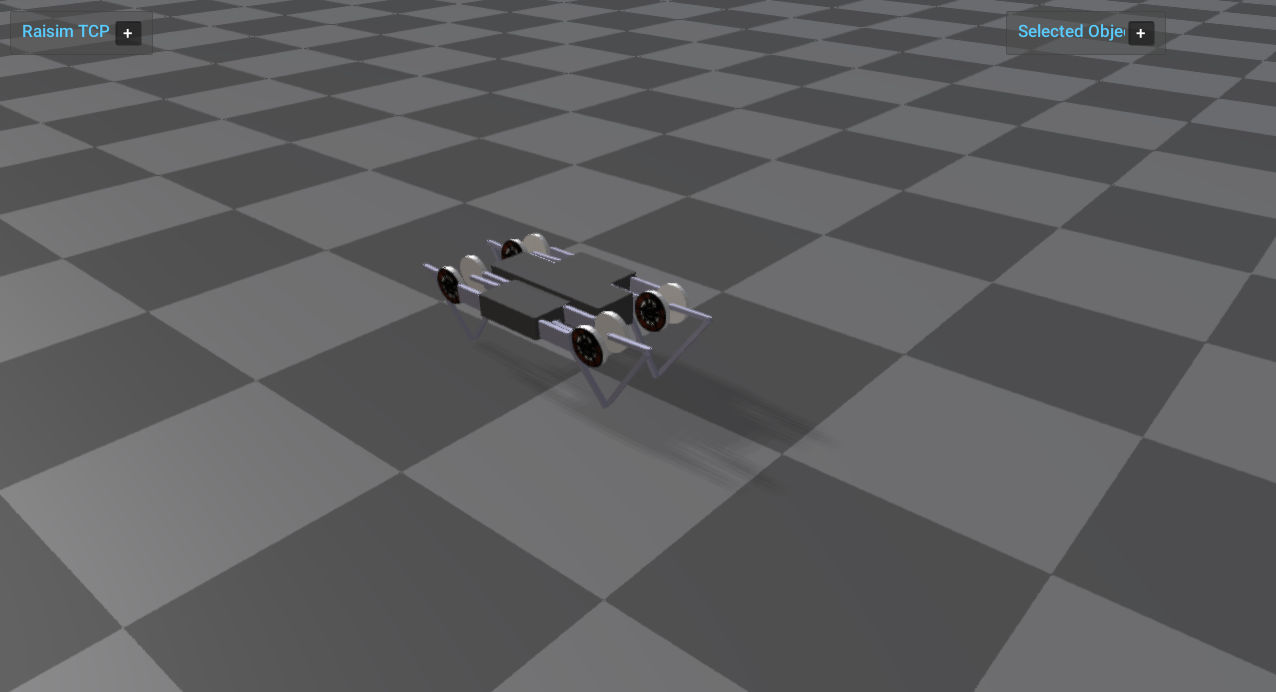
Runs Minitaur with PD control, including per-joint gains that zero out unactuated joints. It is a compact reference for legged robot PD setup.
Screenshot
Target
CMake target: minitaur_pd.
Run
Run the build-tree executable:
bash
./build-examples/examples/minitaur_pdOn Windows, run minitaur_pd.exe instead. This example uses RaisimServer. Start rayrai_tcp_viewer and connect to port 8080.
Details
- Loads the Minitaur URDF (closed-loop) and applies PD to actuated joints.
- Sets gains to zero for unactuated joints in the closed-loop model.
- Focuses the camera on the robot to show posture stability.