
Server Example: Procedural Heightmap
Overview
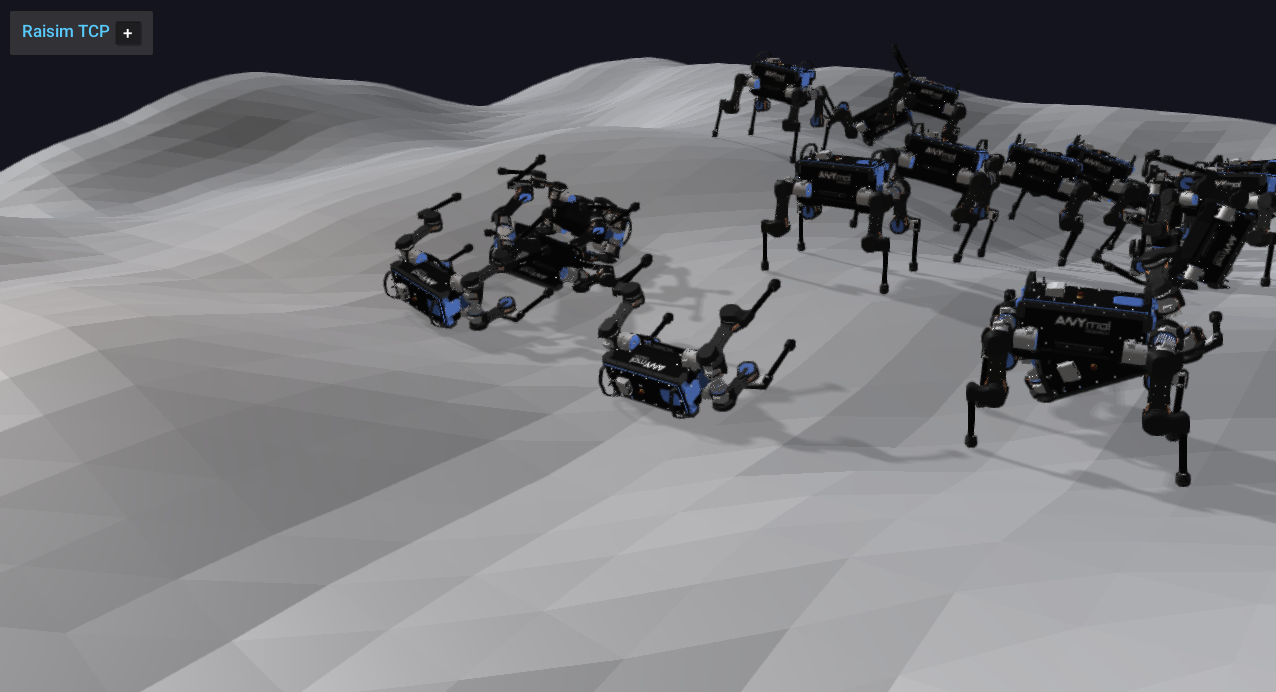
Creates a procedural heightmap and drops a grid of ANYmal robots onto it. Use it to see how to configure fractal terrain properties and run robots on generated terrain.
Screenshot
Target
CMake target: procedural_heightmap.
Run
Run the build-tree executable:
bash
./build-examples/examples/procedural_heightmapOn Windows, run procedural_heightmap.exe instead. This example uses RaisimServer. Start rayrai_tcp_viewer and connect to port 8080.
Details
- Generates terrain from
TerrainProperties(fractal noise). - Spawns a 6 × 6 grid of ANYmal robots above the heightmap with joint PD gains.
- Demonstrates procedural heightmap creation and appearance; see Height Map.