
Server Example: Sensor Suite
Overview
Demonstrates the RGB camera, depth camera, IMU, and LiDAR sensors on ANYmal, including depth-to-point-cloud conversion and point-cloud visualization. It is the main reference for the sensor APIs; see Sensors.
Screenshot
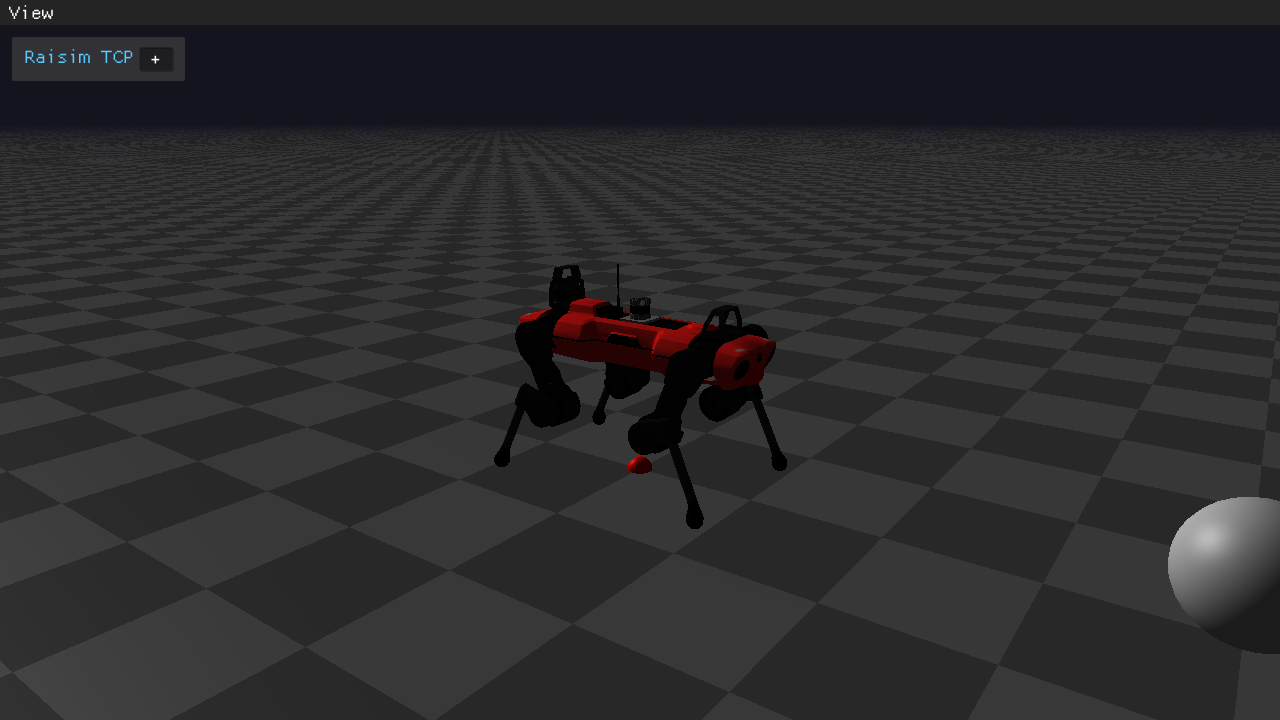
Target
CMake target: sensor_suite. The source is examples/src/server/sensor_suite.cpp.
Run
Start the viewer, then run the build-tree example:
bash
# Terminal 1
./build-examples/examples/rayrai_tcp_viewer

# Terminal 2
./build-examples/examples/sensor_suite
On Windows, run sensor_suite.exe instead. The example uses RaisimServer on port 8080.
Details
- Loads
anymal_c/urdf/anymal_sensored.urdf, which carries front and rear RGB/depth cameras, an IMU, and a spinning LiDAR. - Configures the RGB and depth cameras with
MeasurementSource::MANUAL. The TCP viewer renders these camera frames on request, returns BGRA and metric depth buffers toRaisimServer, and shows previews in the Sensors tab of the selected ANYmal. The source includes a commented-out line that switches the front depth camera to RaiSim CPU depth. - Select the ANYmal, open Sensors, and use Show frustum to inspect the camera pose and range in the main scene.
- Converts the front depth array to 3D points with
DepthCamera::depthToPointCloudand reads the LiDAR scan. - Streams the latest LiDAR scan as a point cloud and two marker spheres through
RaisimServer.