
Server Example: Ray Scan LiDAR
Overview
Sweeps rays from a frame on a Husky robot to emulate a LiDAR scan and visualizes the hits with instanced boxes. This is a compact example of ray-based sensing; see Ray Test.
Screenshot
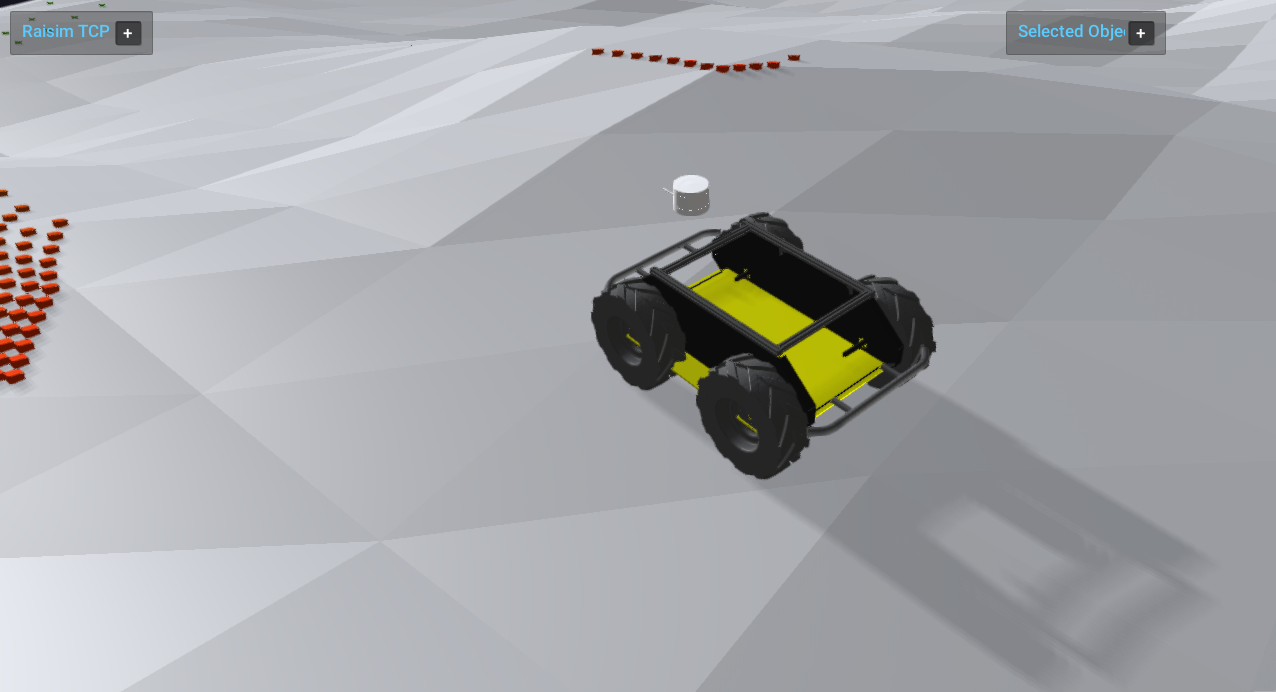
Target
CMake target: ray_scan_lidar.
Run
Run the build-tree executable:
bash
./build-examples/examples/ray_scan_lidarOn Windows, run ray_scan_lidar.exe instead. This example uses RaisimServer. Start rayrai_tcp_viewer and connect to port 8080.
Details
- Sweeps a yaw/pitch grid and uses
rayTestto emulate LiDAR. - Displays scan points as instanced boxes colored by range.
- Uses an IMU frame for ray orientation and resets the robot when out of bounds.