
Server Example: MJCF Gymnasium Hopper
Overview
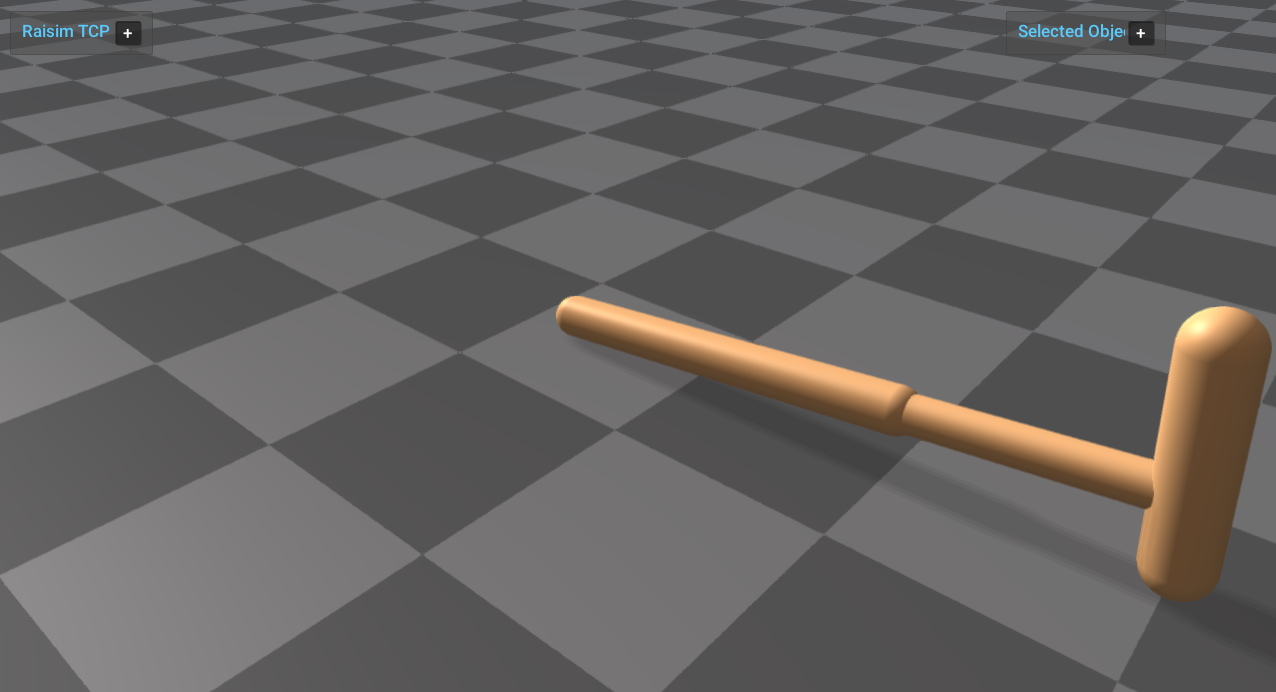
Loads the Gymnasium Hopper MuJoCo XML asset through raisim::World and publishes it through raisim::RaisimServer. The planar model's root moves on two slide joints and one hinge, and the source MJCF uses capsule geoms, a plane, defaults, materials, and actuators.
Target
CMake target: mjcf_gymnasium_hopper.
Run
Run the build-tree executable:
bash
./build-examples/examples/mjcf_gymnasium_hopperOn Windows, run mjcf_gymnasium_hopper.exe instead. This example uses RaisimServer. Start rayrai_tcp_viewer and connect to port 8080.
Details
- Loads
rsc/mjcf/gymnasium/hopper.xmlwith theraisim::Worldconstructor and prints the DOF, generalized-coordinate dimension, and collision-body count. - Retrieves the loaded articulated system by its MJCF root body name (
torso). - Applies a small sinusoidal torque pattern to the leg joints in
FORCE_AND_TORQUEcontrol mode.