
Server Example: Shadow Hand USD Cube
Overview
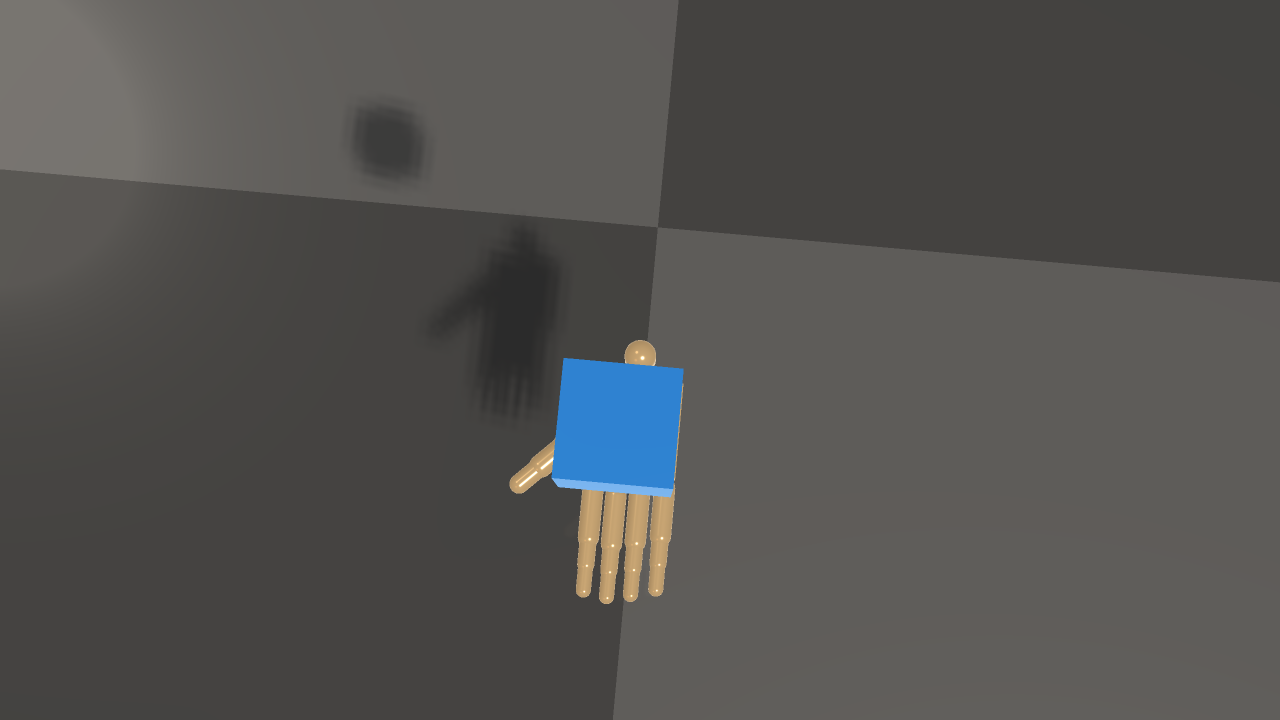
Loads NVIDIA Isaac Sim's Shadow Robot ShadowHand USD scene directly with World(shadow_hand.usd) and places a RaiSim rigid-body cube at the Isaac Lab in-hand cube start pose. The constructor imports the USD Physics rigid bodies and joints as a RaiSim articulated system. See OpenUSD Loading.
The cube is a native RaiSim box. The example fails fast if the ShadowHand articulation, collision bodies, or visual meshes are not imported.
Target
CMake target: shadow_hand_usd_cube (C++20).
Run
Run the build-tree executable:
bash
./build-examples/examples/shadow_hand_usd_cubeOn Windows, run shadow_hand_usd_cube.exe instead. This example uses RaisimServer. Start rayrai_tcp_viewer and connect to port 8080. The viewer remains interactive while the simulation runs.
Details
- Loads
rsc/isaac/Robots/ShadowRobot/ShadowHand/shadow_hand.usdwith theWorldconstructor. - Uses RaiSim's bundled OpenUSD runtime directly; no Assimp USD importer or USD-specific build switch is required.
- Throws an error if the imported scene does not contain an articulated system named
shadow_handwith collision bodies and visual meshes. - Places the ShadowHand base at
(0, 0, 0.5). - Drives the hand toward the imported nominal configuration with PD control. While the viewer has the simulation paused, joint positions edited in the viewer become the new PD targets.
- Creates a dynamic 6.5 cm cube at
(0, -0.39, 1.05), matching the Isaac Lab Shadow Hand cube task's initial object pose.