
Server Example: NVIDIA USD Robots
Overview
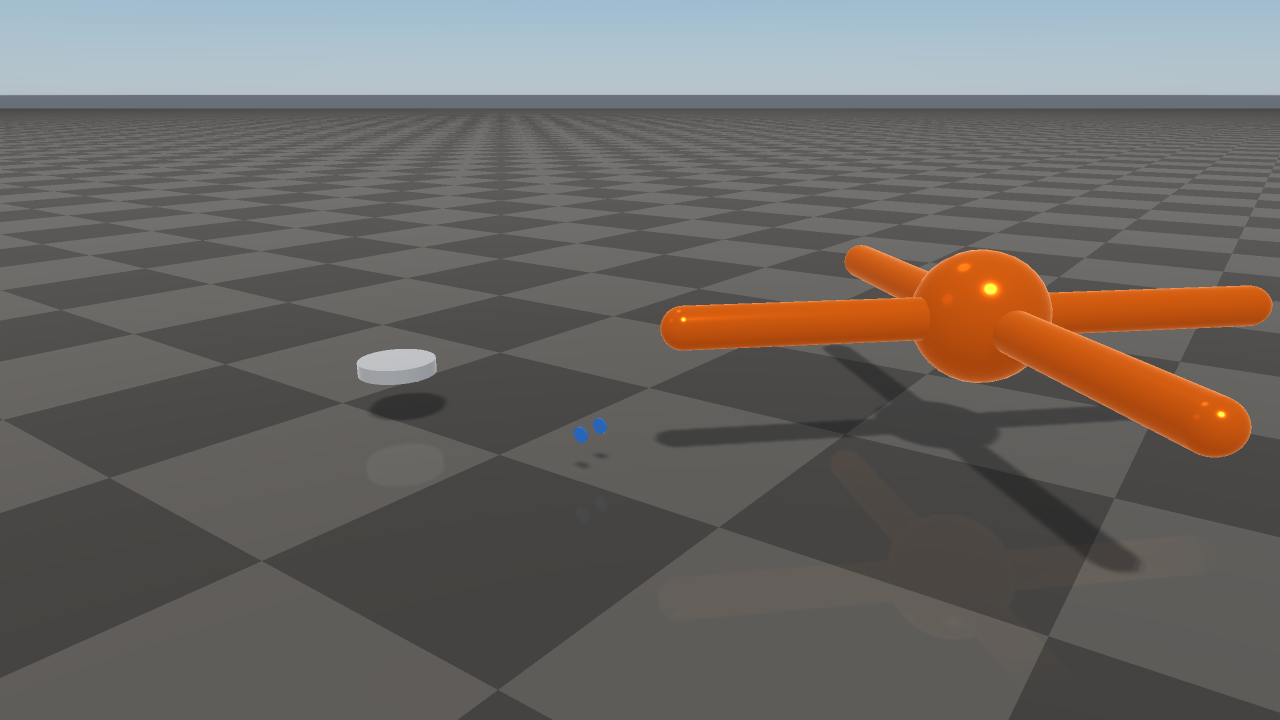
Loads three bundled Isaac Sim robot USD files with World::addUsdArticulatedSystem and publishes them together through RaisimServer. The example is intentionally limited to assets that were smoke-tested as RaiSim articulated systems with supported collision bodies. See OpenUSD Loading.
Target
CMake target: nvidia_usd_robots (C++20). RaiSim loads USD through its bundled OpenUSD runtime on every supported platform, so no extra build switch is needed.
Assets
The bundled assets are:
create3:rsc/isaac/Robots/iRobot/Create3/create_3.usd(BSD-3)jetbot:rsc/isaac/Robots/NVIDIA/Robomaker/aws_robomaker_jetbot.usd(MIT)ant:rsc/isaac/Robots/IsaacSim/Ant/ant.usd(MIT)
Run
Run the build-tree executable:
bash
./build-examples/examples/nvidia_usd_robotsOn Windows, run nvidia_usd_robots.exe instead. This example uses RaisimServer. Start rayrai_tcp_viewer and connect to port 8080.
Details
- Loads each USD file with
World::addUsdArticulatedSystemand simulates at 500 Hz. - Throws an error if a USD file does not import as an articulated system or if no supported collision bodies are imported.
- Places the imported floating bases above a checkerboard ground and applies a shared
nvidia_usd_robotcollision material.