
Server Example: MJCF Gymnasium Humanoid
Overview
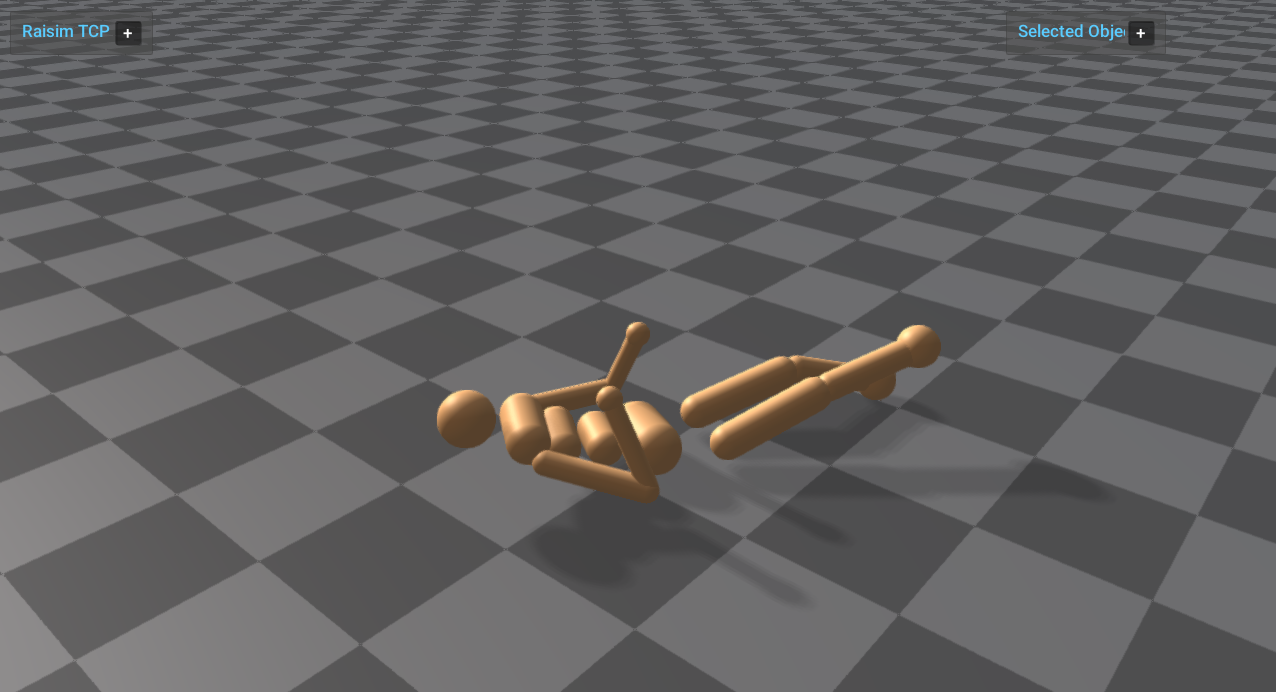
Loads the Gymnasium Humanoid MuJoCo XML asset through raisim::World and publishes it through raisim::RaisimServer. The humanoid starts in a nonzero joint configuration with its base about 1 m above the standing pose and then drops under gravity with zero applied generalized force.
Target
CMake target: mjcf_gymnasium_humanoid.
Run
Run the build-tree executable:
bash
./build-examples/examples/mjcf_gymnasium_humanoidOn Windows, run mjcf_gymnasium_humanoid.exe instead. This example uses RaisimServer. Start rayrai_tcp_viewer and connect to port 8080.
Details
- Loads
rsc/mjcf/gymnasium/humanoid.xmlwith theraisim::Worldconstructor and retrieves the articulated system by its root body name (torso). - Handles a larger MJCF articulated system with a free root and many child bodies.
- Sets an initial free-root pose and a nonzero joint configuration before dropping the model under gravity.