
Server Example: Kinova Arm
Overview
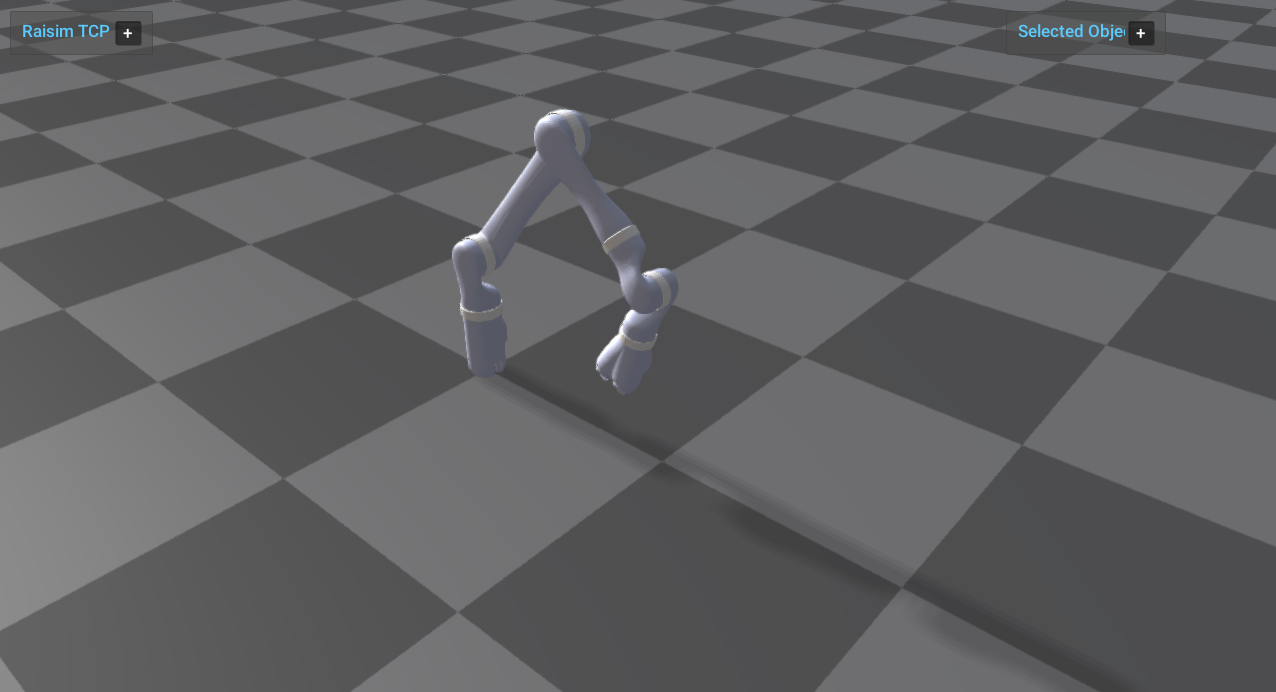
Loads the Kinova arm, applies joint PD gains and targets, and runs it on flat ground. This example focuses on manipulator setup and joint-level control.
Target
CMake target: kinova_arm.
Run
Run the build-tree executable:
bash
./build-examples/examples/kinova_armOn Windows, run kinova_arm.exe instead. This example uses RaisimServer. Start rayrai_tcp_viewer and connect to port 8080.
Details
- Loads the Kinova arm URDF on flat ground and applies joint PD gains/targets.
- Uses a simple scene for fast rendering.
- Focuses the camera on the arm for a fixed-base articulation demo.