
Rayrai Example: Deformable Terrain
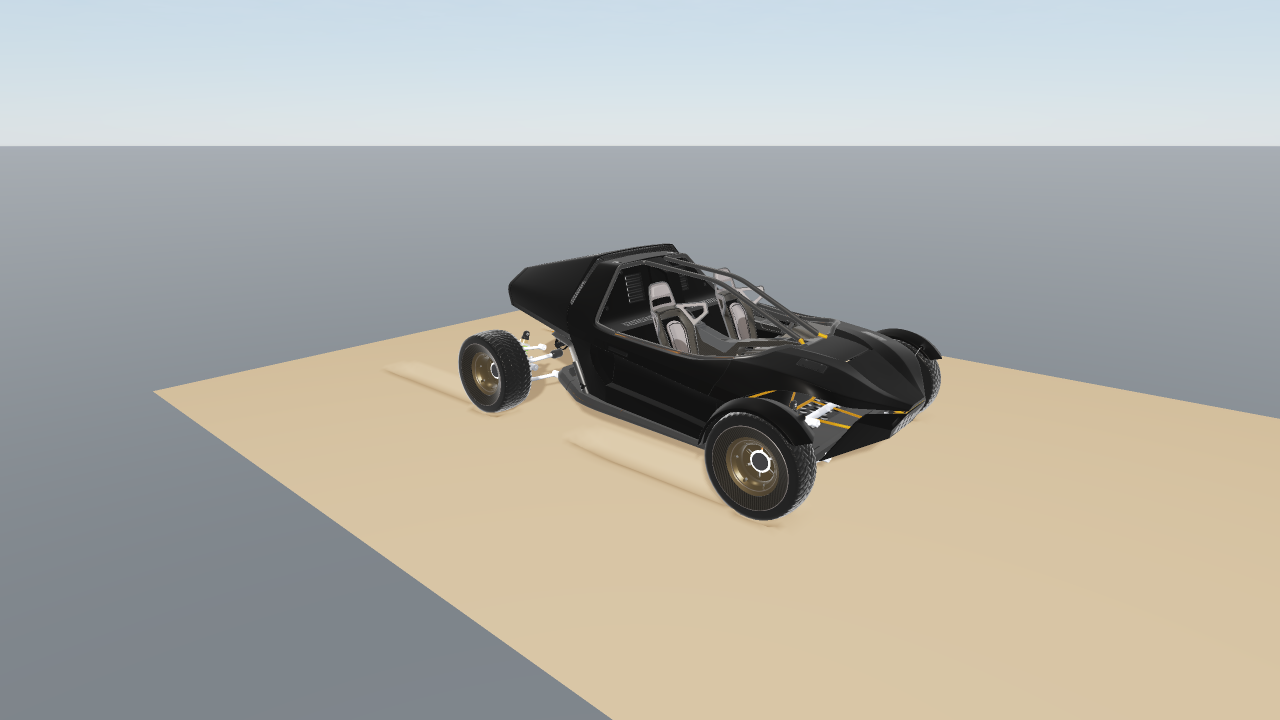
The buggy and its dampers are licensed under CC BY 4.0 and credited in Asset Credits.
Overview
An off-road buggy drives automatically across a 16 m by 6 m soil bed, leaving permanent wheel ruts. The deformable height mesh responds to the wheel loads and slip, while the buggy's double-wishbone suspension follows the changing surface. The camera follows the car.
The example renders in process with raisin::RayraiWindow; it needs no TCP viewer. See Deformable terrain for the soil model and Off-Road Buggy for the vehicle.
Run
./build-examples/examples/rayrai_deformable_terrainOn Windows, run build-examples/bin/rayrai_deformable_terrain.exe.
CMake target: rayrai_deformable_terrain. Source: examples/src/rayrai/physics/rayrai_deformable_terrain.cpp. The example reads the buggy's URDF and meshes from rsc/offroad_buggy, which CMake copies next to the executables.
To run without a window for a fixed number of physics steps:
./build-examples/examples/rayrai_deformable_terrain --headless --steps=3000Options: --hidden renders in a hidden window; --steps=N limits the number of physics steps; --export=DIR saves the world as world.xml and its assets; --activation-key=FILE selects a RaiSim activation key.
Details
World::addDeformableTerraincreates a 201 by 76 sample soil mesh.- Physics runs at a 1 ms time step, with 16 steps per rendered frame.
- The driver maintains about 0.8 m/s and brakes near the end of the bed.
- On exit, the example reports the car's speed, wheel loads, suspension loop error, terrain contact rows and maximum permanent rut depth, and checks that the car and soil state remain finite.