
Server Example: Robotiq Gripper Mimic
Overview
A fixed-base, six-axis Kinova arm carries a wrist-mounted Robotiq 2F-85 through predefined joint positions to pick up a cube at the blue marker and release it at the green marker. The arm returns to its starting pose, resets the world, and repeats the 21.5-second cycle. All motion during the task comes from joint PD control and physical contacts.
The gripper is driven by its left knuckle. Its five other finger joints remain passive and follow through URDF <mimic> constraints (see Mimic Joints).
Screenshot
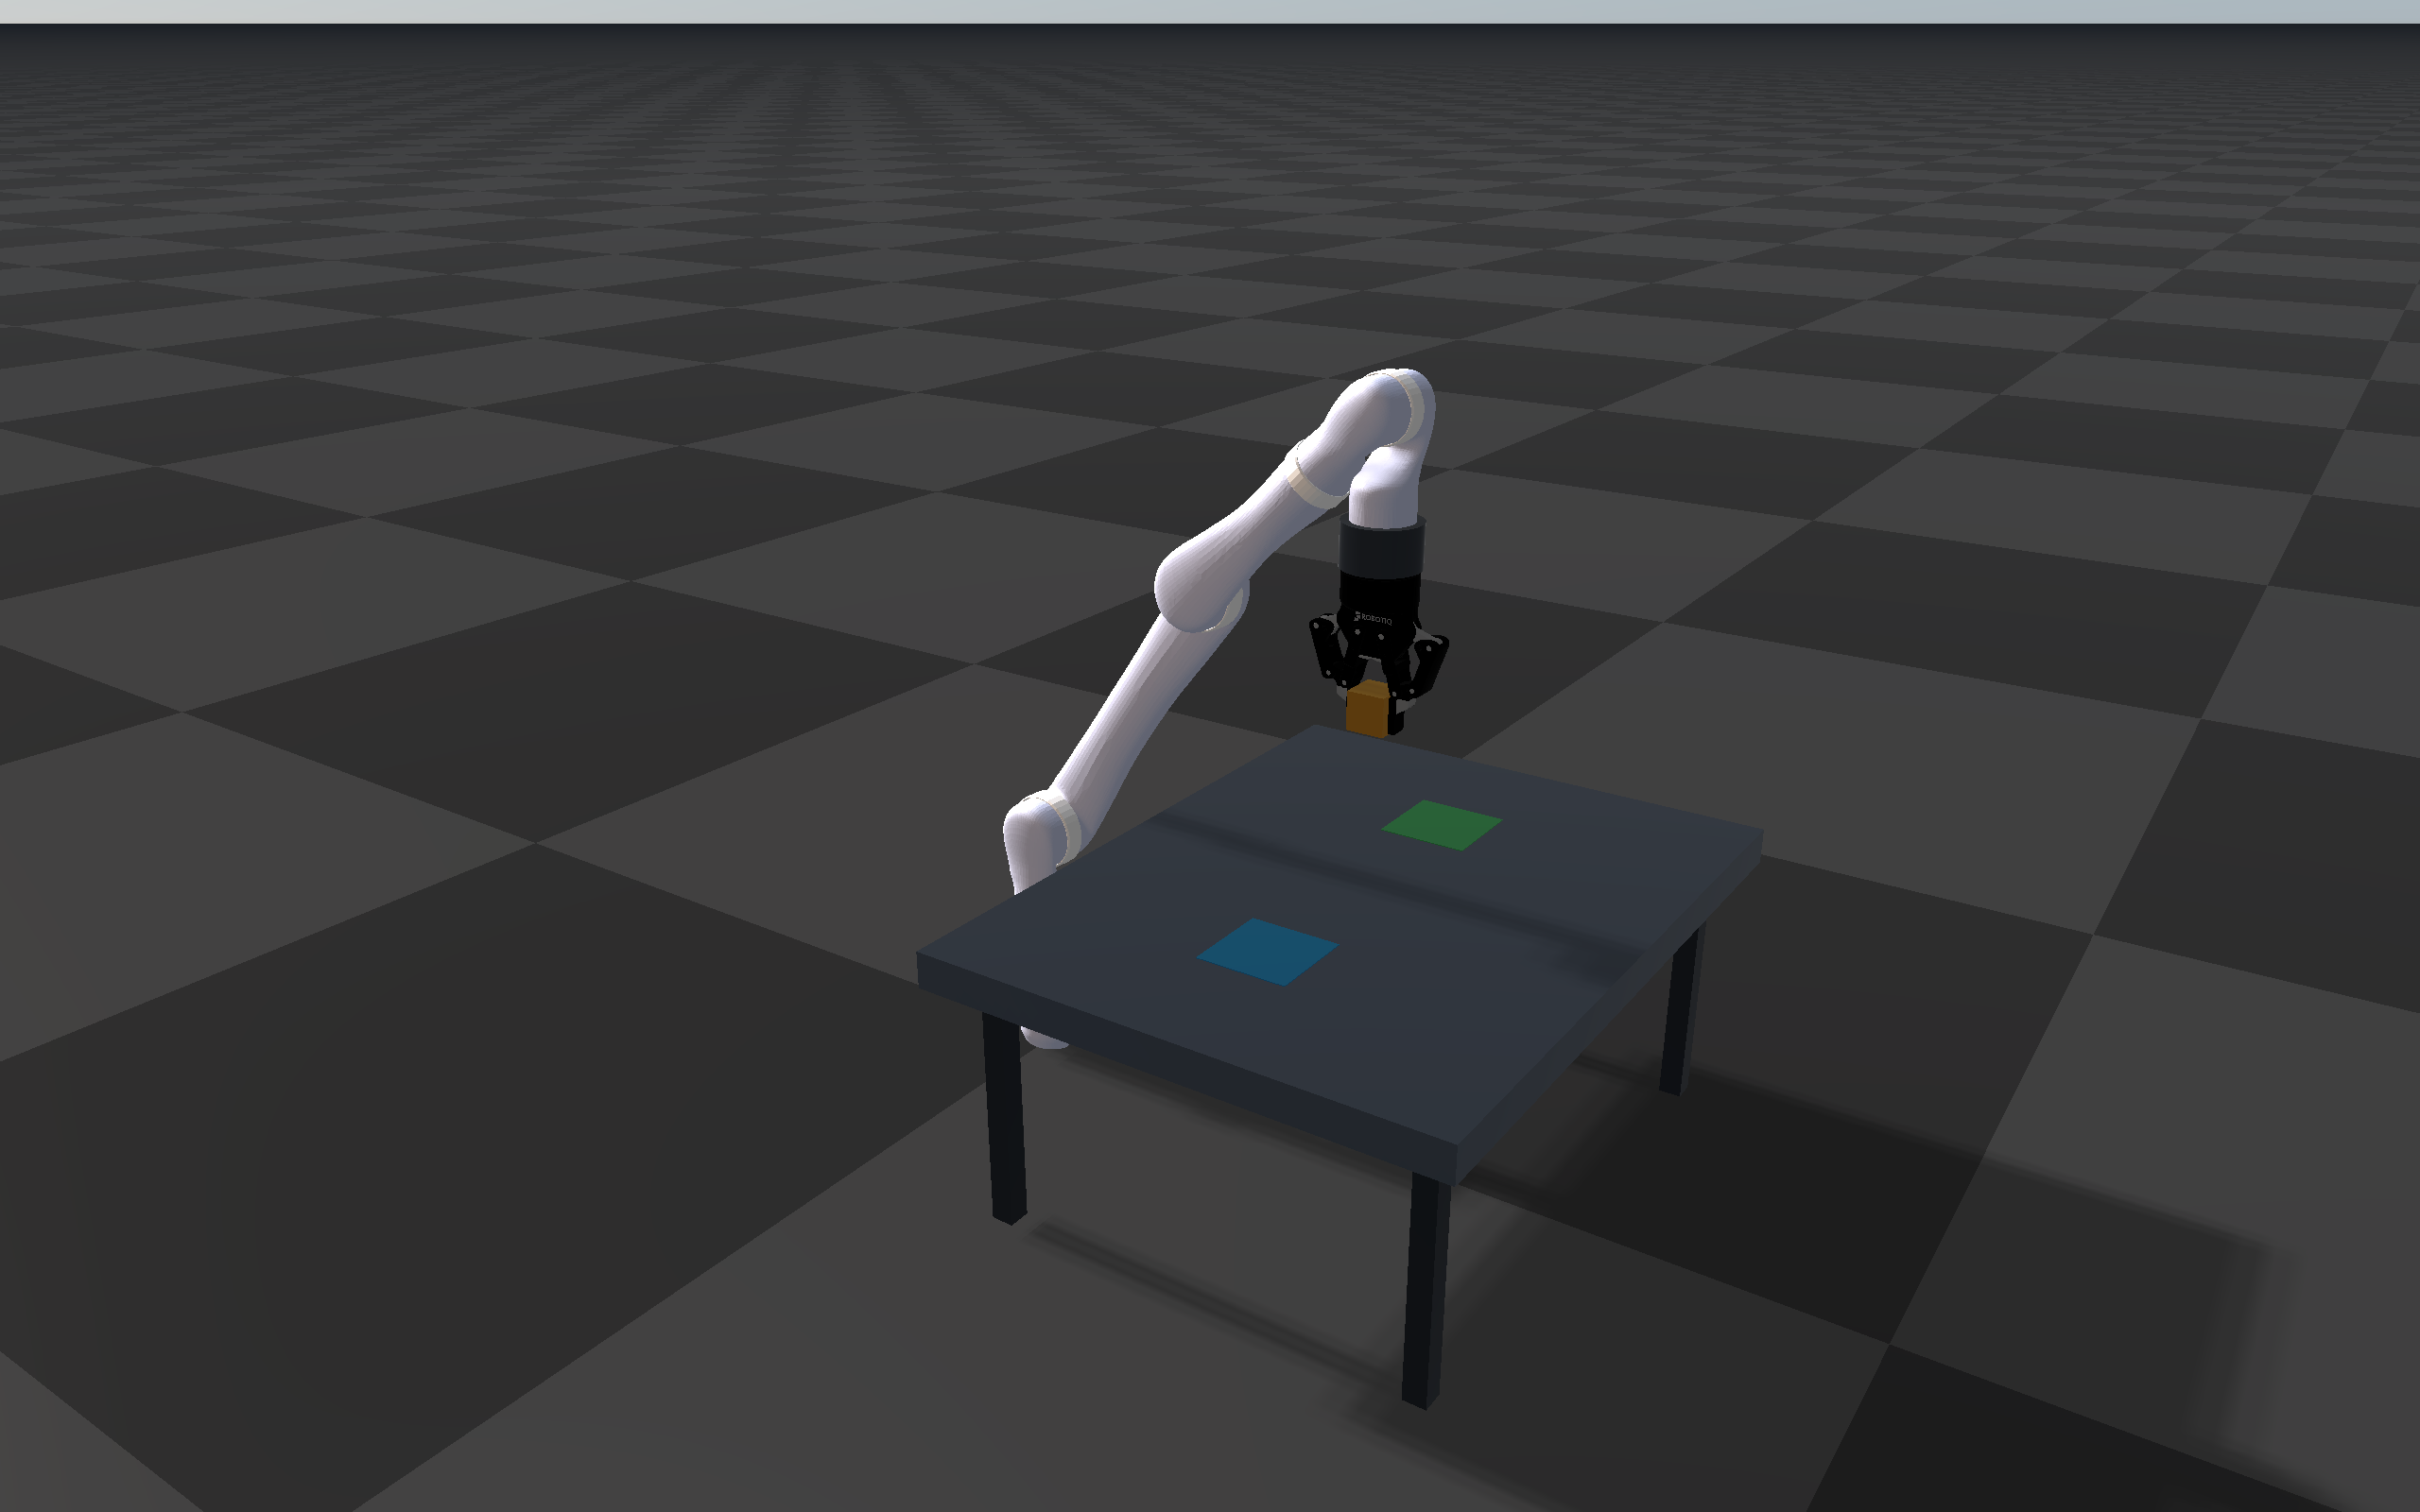
Target
CMake target: robotiq_gripper_mimic.
Run
Run the build-tree executable and connect rayrai_tcp_viewer to port 8080:
./build-examples/examples/robotiq_gripper_mimicOn Windows, run build-examples/bin/robotiq_gripper_mimic.exe instead. The example discovers its resource folder relative to the executable or working directory. Normal RaiSim license discovery applies; use --activation-key /path/to/activation.raisim for an explicit license. --port N changes the server port. The example repeats until interrupted; --cycles N stops it after N cycles.
Details
- Loads
rsc/robotiq_2f85/kinova_robotiq.urdf. The combined model reuses the bundled BSD-licensed Kinova arm and Robotiq descriptions and meshes. A fixed flange replaces the Kinova three-finger hand and the verticalliftjoint of the standalone gripper model (rsc/robotiq_2f85/robotiq_2f85_mimic.urdf). - Only the six arm joints and
robotiq_85_left_knuckle_jointhave PD gains. The five mimic followers have zero gains; the fingertips counter-rotate so the pads remain parallel. - The cube is 40 mm on each side and weighs 100 g. It moves 360 mm between the table markers and rises about 200 mm during transfer.
- Four predefined arm configurations specify pickup, pickup hover, destination hover, and placement. A quintic interpolation supplies continuous position and velocity targets with zero velocity and acceleration at phase boundaries. Changing the model or marker positions requires updating these configurations.
- The closing target goes past the cube width, so the knuckle PD squeezes the cube. Pad friction supports the cube throughout lifting and transfer.
- After release, retraction, and return, the example restores a checkpoint of the settled initial world, including robot/cube state and solver history. The cube is repositioned only by this explicit reset at the cycle boundary.
- Controller updates run inside the RaisimServer world mutex and follow simulation time, so viewer pause and queued single-step pause the sequence.