Server Example: Strandbeest Closed Loops
Overview
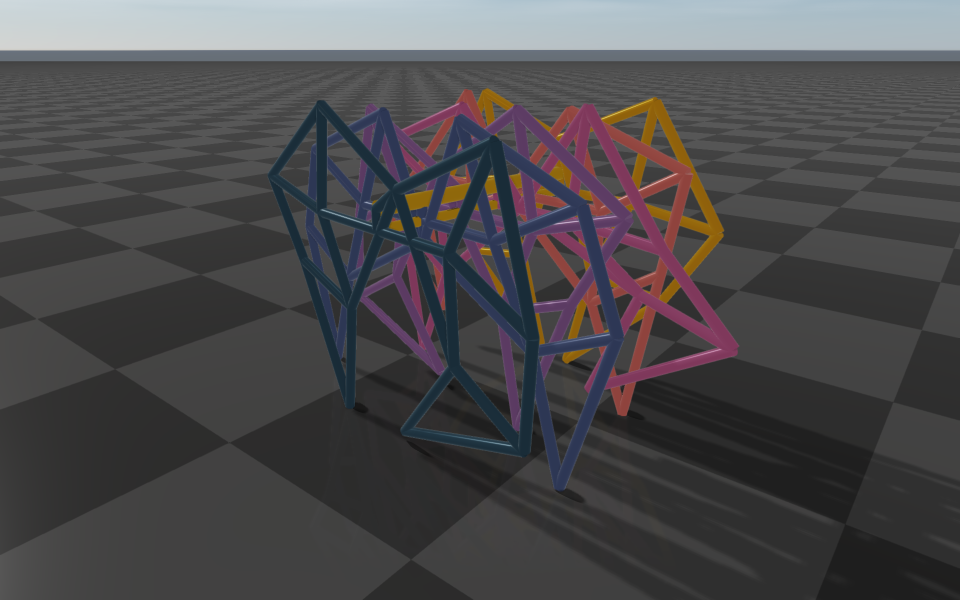
A 12-legged Strandbeest walks, driven by one crank. Its 36 closed kinematic loops are closed by
URDF <equality> constraints (see Closed-Loop Systems).
Screenshot
Target
CMake target: strandbeest_closed_loops.
Run
Run the build-tree executable:
./build-examples/examples/strandbeest_closed_loops
On Windows, run strandbeest_closed_loops.exe instead.
This example uses RaisimServer. Start rayrai_tcp_viewer and connect to port 8080.
Details
Loads
rsc/strandbeest/strandbeest.urdf, converted from the MIT-licensed StrandbeestRobot.jl model: 79 degrees of freedom and 36 loop constraints.Every loop is planar, so each loop hinge is an equality constraint along the two axes normal to its hinge axis. Closing them with two pins per hinge instead gives the same motion, but doubles the number of constraint rows (half of them redundant) and made a step about 3.5 times slower.
The constraints are eliminated exactly every step, so the contact solver only iterates on the feet’s ground contacts (about two sweeps per step).
The crank
joint_crossbar_crankturns at one revolution per second through a velocity-only PD; every other joint is passive. The Strandbeest walks about 1.3 m per crank revolution.